AnswersPublished20 sources
Unitree Dex5-S: Specs, Price and How It Compares With Dex5-1
Unitree’s Dex5 S is a human sized, five finger robotic hand announced on September 21, 2026. It weighs about 620 g and is rated for a 1 kg continuous load or 2 kg maximum load.
Published byEdited with GPT-6 SolImages generated with GPT Image 2
Research answer
Key takeaways
- Unitree’s Dex5 S is a human sized, five finger robotic hand announced on September 21, 2026.
- It weighs about 620 g and is rated for a 1 kg continuous load or 2 kg maximum load.
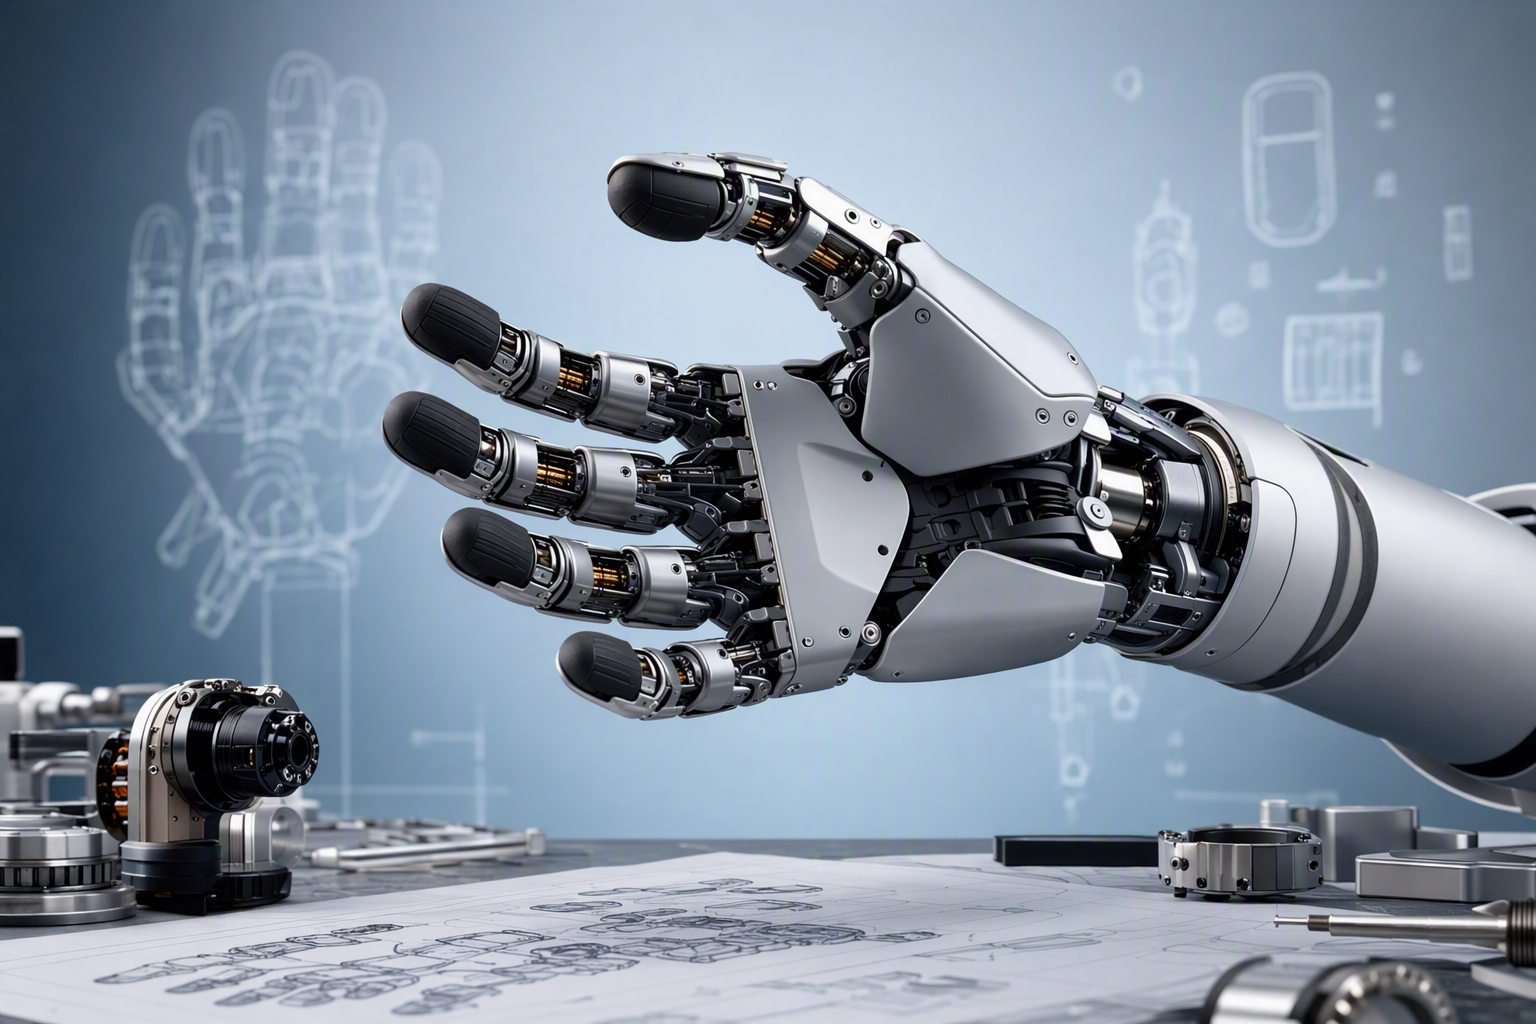
AI Prompt
openai.comCreate a landscape editorial hero image for this Studio Global article: What is Unitree’s Dex5-S, and how do its human-sized five-finger design, 22 fully motor-driven and backdrivable degrees of freedom, dual-enc. Article summary: Unitree’s Dex5-S is a human-sized, five-finger robotic hand for dexterous manipulation, announced in September 2026. Its main advance over Unitree’s earlier Dex5-1 is not merely two more degrees of freedom: Unitree descr. Topic tags: general, general web, user generated. Style: premium digital editorial illustration, source-backed research mood, clean composition, high detail, modern web publication hero. Use reference image context only for broad subject, composition, and topical grounding; do not copy the exact image. Avoid: logos, brand marks, copyrighted characters, real person likenesses, fake screenshots, UI text, readable text, watermarks, charts with fa
Unitree’s Dex5-S is a five-finger robotic hand, not a new humanoid robot. Announced on September 21, 2026, it puts 22 motor-driven degrees of freedom into a roughly human-sized hand intended for dexterous manipulation. Its clearest advance over the earlier Dex5-1 is the number of actively driven axes—not simply the total joint count. 9
16
26
What the Dex5-S adds
The Dex5-S measures 102 × 187 × 26 mm and weighs about 620 g. Its 22 degrees of freedom are distributed across the thumb and little finger at five each, with four each in the index, middle and ring fingers. The little finger gains a roll axis, which gives controllers another way to position it during a grasp; that design change is not, on its own, proof of better results in a particular task. 3
9
Reports of the launch describe 22 motors with dual-encoder control. Unitree says all 22 joints are backdrivable and have individual impact-torque protection. Backdrivability lets an external force move a joint rather than encountering a rigidly held position, but neither that feature nor torque protection establishes that the hand is safe for unrestricted contact with people. 9
16
17
The reported ratings are 1 kg continuous load, 2 kg maximum load and 200 W peak power. The starting price is RMB 39,900 in China; Unitree advertises $6,500 internationally, excluding tax and shipping. Neither figure is a complete installed-system cost. 9
16
How it compares with Dex5-1—and other research hands
Unitree lists the Dex5-1 at 20 degrees of freedom, 16 active, and 1,100 g. It also describes backdrivable finger joints and lists a tactile-sensing configuration. The Dex5-S therefore should not be described as Unitree’s first backdrivable five-finger hand: the meaningful distinction is 22 motorized axes in a substantially lighter design. 25
26
Touch sensing needs a version-by-version comparison. Launch coverage says the Dex5-S Pro adds tactile sensing, while the standard Dex5-S and Pro share the 22-degree-of-freedom layout. More powered joints do not necessarily mean more tactile feedback. Published starting prices and specifications are useful screening information, but the provided evidence does not establish a like-for-like price or manipulation-performance ranking against other research-grade hands. 6
20
25
Where it fits—and what buyers still need to verify
As a hand component, the Dex5-S is relevant to humanoid manipulation, teleoperation and research on grasping or handling objects; it is not an announcement that every Unitree humanoid ships with one. Unitree separately says its UnifoLM-WLA-1.0 model supports two-finger grippers and multiple five-finger hands. That statement does not identify Dex5-S as a demonstrated or bundled end effector for the model. 11
23
Launch reports list a 15–65 V supply and Ethernet, USB and RS-485 communication options. Before planning an integration, developers would still need to confirm the applicable mounting and software support, joint-level torque and speed data, encoder accuracy, tactile configuration by version, durability and performance on a specific robot. A stated communication or control rate should not be mistaken for measured end-to-end latency. 6
9
17
Studio Global AI
Continue your research
This page includes a source-backed answer you can continue inside Studio Global.
People also ask
What is the short answer to "Unitree Dex5-S: Specs, Price and How It Compares With Dex5-1"?
Unitree’s Dex5 S is a human sized, five finger robotic hand announced on September 21, 2026.
What are the key points to validate first?
Unitree’s Dex5 S is a human sized, five finger robotic hand announced on September 21, 2026. It weighs about 620 g and is rated for a 1 kg continuous load or 2 kg maximum load.