AnswersPublished17 sources
How Unitree UniUni Coordinates Humanoid Robot Performances
Unitree UniUni is a free Windows and macOS app for coordinating H2 and G1 humanoids, with visual path planning, timed choreography and fleet monitoring.
Published byEdited with GPT-6 LunaImages generated with GPT Image 2
Research answer
Key takeaways
- Unitree UniUni is a free Windows and macOS app for coordinating H2 and G1 humanoids, with visual path planning, timed choreography and fleet monitoring.
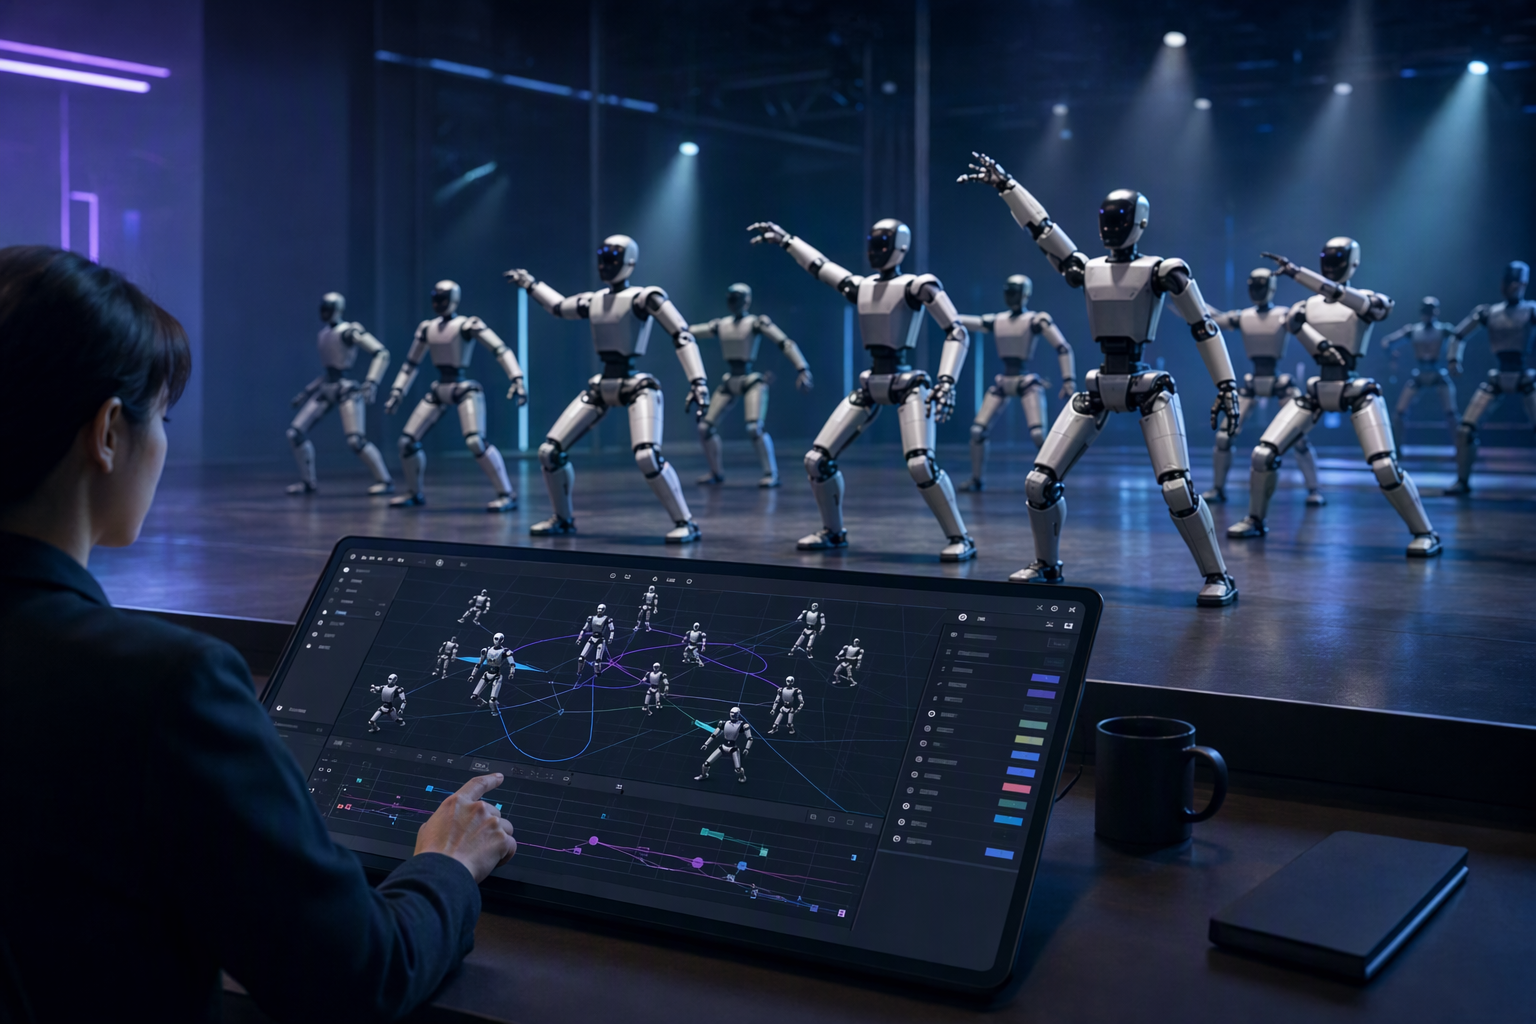
AI Prompt
openai.comCreate a landscape editorial hero image for this Studio Global article: What is Unitree Robotics’ UniUni swarm-control software, released as reported on October 17, 2026, and how does it enable customers to chore. Article summary: UniUni is Unitree Robotics’ desktop software for planning, coordinating and supervising groups of humanoid robots through one interface, particularly for choreographed performances. Reports published on October 17, 2026 . Topic tags: general, general web, user generated. Style: premium digital editorial illustration, source-backed research mood, clean composition, high detail, modern web publication hero. Use reference image context only for broad subject, composition, and topical grounding; do not copy the exact image. Avoid: logos, brand marks, copyrighted characters, real person likenesses, fake screenshots, UI text, readable text, watermarks, charts with fa
Unitree UniUni is a desktop tool for planning and supervising multiple Unitree humanoids through one interface. Reported features include visual trajectory planning, timed actions, movement synchronized to music and fleet monitoring. It is aimed at coordinated performances—not proof of industrial-grade autonomous swarm operation. 3
5
10
What UniUni offers
UniUni is reported to be free for Unitree customers, available on Windows and macOS, and initially compatible with the H2 and G1 humanoids. 3
10
Operators can plan robot paths and arrange actions on timelines, helping coordinate where robots move and when they act. Coverage also describes LiDAR mapping and formation monitoring, as well as choreography set to music. 5
10 Some reporting mentions natural-language choreography, but the available sources do not establish that the software automatically generates complete whole-body motion.
4
8
The app is also described as supporting automatic robot discovery on a shared network, live status monitoring and a group emergency stop. 2
3 Together, these features give operators a single place to prepare and oversee a performance rather than managing each robot’s movements in isolation.
What the launch does—and does not—establish
UniUni’s visual planning and monitoring features address practical coordination needs: timing actions, managing formations and watching robot status during a show. 4
5
10 Operators should still plan and rehearse spacing, crossing paths and what to do if a robot or network connection fails. The reported emergency-stop feature is useful, but the available evidence does not show that it replaces a separately validated safety plan.
Important deployment details remain unclear. Reporting says the maximum fleet size, network requirements and positioning accuracy have not been established; complex-environment performance has also not been independently tested. 2
10
31 Claims about specific launch builds, point-cloud imports, laser-SLAM localization and automatic pairing are not sufficiently corroborated in the available sources to treat as confirmed specifications.
The distinction matters: UniUni is presented as a choreography and fleet-supervision tool. Its launch features do not, by themselves, demonstrate reliable autonomous coordination for industrial work. 10
31
Studio Global AI
Continue your research
This page includes a source-backed answer you can continue inside Studio Global.
People also ask
What is the short answer to "How Unitree UniUni Coordinates Humanoid Robot Performances"?
Unitree UniUni is a free Windows and macOS app for coordinating H2 and G1 humanoids, with visual path planning, timed choreography and fleet monitoring.
Sources
hasbrains.comUnitree releases UniUni, a free app to choreograph robot ...
innovationpost.itUniUni, la piattaforma di Unitree per la gestione no-code dei robot - Innovation Post
pandaily.comUnitree Releases UniUni Swarm Control Software, Free for Its Users, Starting With H2 and G1
humanoidsdaily.comUnitree’s UniUni Lets Operators Choreograph Robot Teams With ...