HELIOS: Why This Four‑Armed Space Robot Ditches Legs for Orbital Work
HELIOS is a prototype humanoid robot from Orbit Robotics built specifically for space: instead of legs it uses four arms to move, anchor itself, and perform maintenance tasks in microgravity environments such as space... The robot’s design prioritizes dexterity and stabilization in weightlessness, reflecting a broad...
HELIOS is a prototype humanoid robot from Orbit Robotics built specifically for space: instead of legs it uses four arms to move, anchor itself, and perform maintenance tasks in microgravity environments such as space...
The robot’s design prioritizes dexterity and stabilization in weightlessness, reflecting a broader shift toward manipulator‑based robots for orbital servicing and astronaut assistance.
HELIOS joins a growing global push for space robotics alongside projects like NASA’s Robonaut 2, China’s planned PM01 robot astronaut, and Icarus Robotics’ free‑flying “Joy” robot planned for testing on the ISS in 2027.
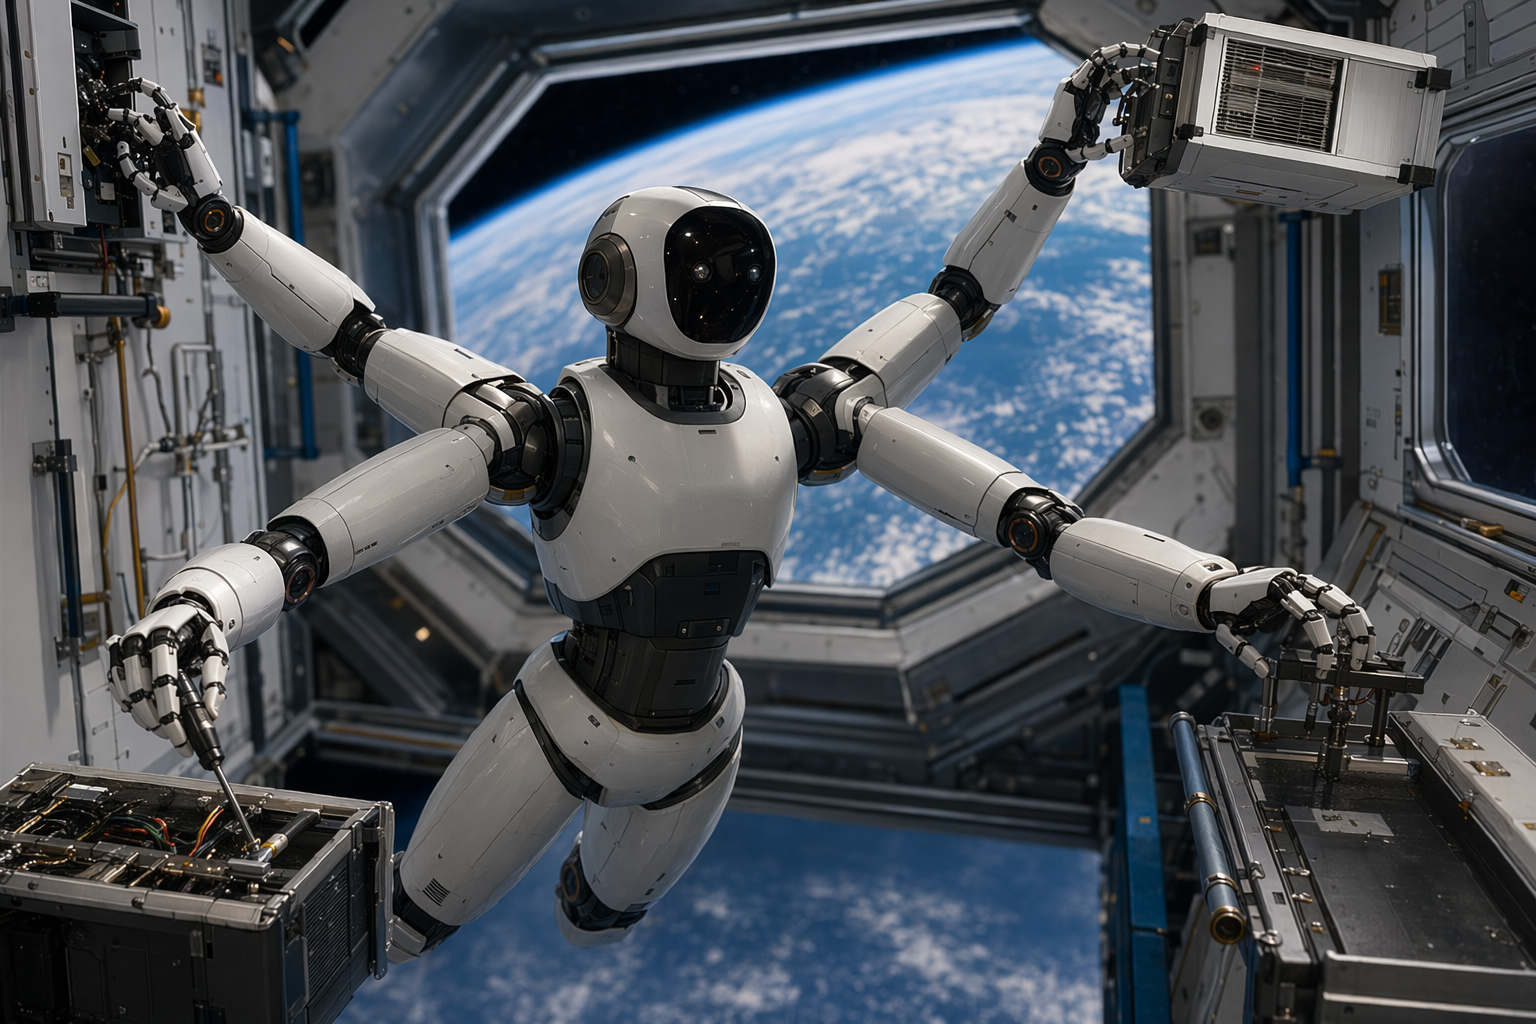
What is Orbit Robotics’ newly unveiled HELIOS robot, how is its legless four‑armed design optimized for microgravity operations in space (inConcept visualization of HELIOS, a four‑armed humanoid robot designed for maneuvering and performing maintenance tasks in microgravity.
AI Prompt
Create a landscape editorial hero image for this Studio Global article: What is Orbit Robotics’ newly unveiled HELIOS robot, how is its legless four‑armed design optimized for microgravity operations in space (in. Article summary: Orbit Robotics’ HELIOS, as described in your prompt, is a prototype space robot designed specifically for microgravity, using a legless body with four arms instead of a humanoid walking form. Based on the available evide. Topic tags: general, general web, user generated, government, academic. Reference image context from search candidates: Reference image 1: visual subject "* HELIOS Humanoid Robot With Four Arms for Orbital Missions. Orbit Robotics, a Canadian robotics firm, has unveiled a new humanoid robot designed specifically for space environment" source context "HELIOS Humanoid Robot With Four Arms for Orbital Missions - Hardware Busters" Reference image
openai.com
Orbit Robotics has unveiled HELIOS, a prototype humanoid robot designed specifically for work in space. Instead of copying the typical human shape with two legs and two arms, HELIOS takes a radically different approach: it replaces legs with two additional arms, creating a four‑armed robotic system optimized for the realities of microgravity.
The concept reflects a simple truth about orbital environments—robots in space do not need to walk. What they need is dexterity, stability, and the ability to maneuver and manipulate equipment in weightlessness.
A Legless Robot Built for Microgravity
HELIOS was created to assist astronauts and perform technical tasks on orbital infrastructure such as space stations or satellites. In promotional demonstrations, the robot appears with a lightweight frame and a network of cable‑driven joints designed to improve precision and control.
Studio Global AI
Continue your research
This page includes a source-backed answer you can continue inside Studio Global.
What is the short answer to "HELIOS: Why This Four‑Armed Space Robot Ditches Legs for Orbital Work"?
HELIOS is a prototype humanoid robot from Orbit Robotics built specifically for space: instead of legs it uses four arms to move, anchor itself, and perform maintenance tasks in microgravity environments such as space...
What are the key points to validate first?
HELIOS is a prototype humanoid robot from Orbit Robotics built specifically for space: instead of legs it uses four arms to move, anchor itself, and perform maintenance tasks in microgravity environments such as space... The robot’s design prioritizes dexterity and stabilization in weightlessness, reflecting a broader shift toward manipulator‑based robots for orbital servicing and astronaut assistance.
What should I do next in practice?
HELIOS joins a growing global push for space robotics alongside projects like NASA’s Robonaut 2, China’s planned PM01 robot astronaut, and Icarus Robotics’ free‑flying “Joy” robot planned for testing on the ISS in 2027.
HELIOS: Why This Four‑Armed Space Robot Ditches Legs for Orbital Work
HELIOS is a prototype humanoid robot from Orbit Robotics built specifically for space: instead of legs it uses four arms to move, anchor itself, and perform maintenance tasks in microgravity environments such as space... The robot’s design prioritizes dexterity and stabilization in weightlessness, reflecting a broad...
HELIOS is a prototype humanoid robot from Orbit Robotics built specifically for space: instead of legs it uses four arms to move, anchor itself, and perform maintenance tasks in microgravity environments such as space...
The robot’s design prioritizes dexterity and stabilization in weightlessness, reflecting a broader shift toward manipulator‑based robots for orbital servicing and astronaut assistance.
HELIOS joins a growing global push for space robotics alongside projects like NASA’s Robonaut 2, China’s planned PM01 robot astronaut, and Icarus Robotics’ free‑flying “Joy” robot planned for testing on the ISS in 2027.
What is Orbit Robotics’ newly unveiled HELIOS robot, how is its legless four‑armed design optimized for microgravity operations in space (inConcept visualization of HELIOS, a four‑armed humanoid robot designed for maneuvering and performing maintenance tasks in microgravity.
AI Prompt
Create a landscape editorial hero image for this Studio Global article: What is Orbit Robotics’ newly unveiled HELIOS robot, how is its legless four‑armed design optimized for microgravity operations in space (in. Article summary: Orbit Robotics’ HELIOS, as described in your prompt, is a prototype space robot designed specifically for microgravity, using a legless body with four arms instead of a humanoid walking form. Based on the available evide. Topic tags: general, general web, user generated, government, academic. Reference image context from search candidates: Reference image 1: visual subject "* HELIOS Humanoid Robot With Four Arms for Orbital Missions. Orbit Robotics, a Canadian robotics firm, has unveiled a new humanoid robot designed specifically for space environment" source context "HELIOS Humanoid Robot With Four Arms for Orbital Missions - Hardware Busters" Reference image
openai.com
Orbit Robotics has unveiled HELIOS, a prototype humanoid robot designed specifically for work in space. Instead of copying the typical human shape with two legs and two arms, HELIOS takes a radically different approach: it replaces legs with two additional arms, creating a four‑armed robotic system optimized for the realities of microgravity.
The concept reflects a simple truth about orbital environments—robots in space do not need to walk. What they need is dexterity, stability, and the ability to maneuver and manipulate equipment in weightlessness.
A Legless Robot Built for Microgravity
HELIOS was created to assist astronauts and perform technical tasks on orbital infrastructure such as space stations or satellites. In promotional demonstrations, the robot appears with a lightweight frame and a network of cable‑driven joints designed to improve precision and control.
Studio Global AI
Continue your research
This page includes a source-backed answer you can continue inside Studio Global.
What is the short answer to "HELIOS: Why This Four‑Armed Space Robot Ditches Legs for Orbital Work"?
HELIOS is a prototype humanoid robot from Orbit Robotics built specifically for space: instead of legs it uses four arms to move, anchor itself, and perform maintenance tasks in microgravity environments such as space...
What are the key points to validate first?
HELIOS is a prototype humanoid robot from Orbit Robotics built specifically for space: instead of legs it uses four arms to move, anchor itself, and perform maintenance tasks in microgravity environments such as space... The robot’s design prioritizes dexterity and stabilization in weightlessness, reflecting a broader shift toward manipulator‑based robots for orbital servicing and astronaut assistance.
What should I do next in practice?
HELIOS joins a growing global push for space robotics alongside projects like NASA’s Robonaut 2, China’s planned PM01 robot astronaut, and Icarus Robotics’ free‑flying “Joy” robot planned for testing on the ISS in 2027.
Its most distinctive feature is its four‑arm architecture. Instead of legs used for walking on the ground, HELIOS uses its additional arms to:
Move through station interiors
Stabilize itself against surfaces
Position its body for maintenance work
This configuration allows the robot to grip structures, reposition itself, and work in tight spaces, which are common constraints inside spacecraft and orbital platforms.
Developers say the design focuses on tasks astronauts frequently perform, including equipment maintenance, cargo handling, and orbital construction activities.
Why Four Arms Make Sense in Space
On Earth, humanoid robots often need legs to navigate floors, stairs, and uneven terrain. In microgravity, those constraints disappear. Instead, the key challenge is controlling movement without drifting away from the worksite.
A multi‑arm robot can solve this by anchoring itself to nearby structures. For example, it could hold onto a frame or handrail with some arms while using others to manipulate tools or equipment. This approach mirrors strategies used in robotic manipulators designed for on‑orbit servicing and spacecraft maintenance.
Because of this, many space‑robotics concepts emphasize manipulator arms, grasping mechanisms, and precise control systems rather than traditional walking locomotion.
Early‑Stage Prototype Status
HELIOS is still an early prototype. Public information about detailed specifications—such as size, weight, lifting capacity, or total degrees of freedom—remains limited in currently available reports.
What is clear is that the robot is intended as a technology demonstrator exploring new ways for robots to move and work in microgravity. The project has been presented as part of a research effort focused on robotic assistants for future orbital operations.
Part of a Growing Space‑Robot Race
HELIOS appears at a time when space agencies and startups worldwide are accelerating efforts to develop robotic workers for orbit.
Several notable projects illustrate the trend:
NASA’s Robonaut 2 (R2)
NASA launched Robonaut 2 to the International Space Station in 2011 aboard Space Shuttle Discovery. It became the first humanoid robot in space, designed to assist astronauts and test how dexterous robots operate in orbit.
China’s PM01 robotic astronaut initiative
Chinese robotics company Engine AI has announced plans to send its PM01 humanoid robot into space as part of a “robot astronaut” exploration program, highlighting growing interest in autonomous robotic crew members for hazardous tasks.
Icarus Robotics’ “Joy” robot (ISS mission planned for 2027)
Startup Icarus Robotics is developing a free‑flying robot called Joy that is scheduled for testing aboard the International Space Station in early 2027. The mission will evaluate autonomous navigation and robotic operations in a real space‑station environment.
Together, these projects reflect a broader industry shift: robots are increasingly expected to handle inspection, repair, assembly, and logistics tasks in orbit, reducing risk for human astronauts.
The Bigger Idea Behind HELIOS
HELIOS illustrates how engineers are rethinking robotics for space rather than simply adapting Earth‑based designs. By abandoning legs and focusing on multi‑arm dexterity and anchoring, the robot’s structure directly matches the physics of microgravity.
If future versions mature beyond the prototype stage, robots like HELIOS could eventually help astronauts maintain spacecraft, assemble large orbital structures, and manage cargo operations—turning space stations into workplaces where humans and robots collaborate side by side.
frontiersin.org
A comprehensive survey of space robotic manipulators for ...
Its most distinctive feature is its four‑arm architecture. Instead of legs used for walking on the ground, HELIOS uses its additional arms to:
Move through station interiors
Stabilize itself against surfaces
Position its body for maintenance work
This configuration allows the robot to grip structures, reposition itself, and work in tight spaces, which are common constraints inside spacecraft and orbital platforms.
Developers say the design focuses on tasks astronauts frequently perform, including equipment maintenance, cargo handling, and orbital construction activities.
Why Four Arms Make Sense in Space
On Earth, humanoid robots often need legs to navigate floors, stairs, and uneven terrain. In microgravity, those constraints disappear. Instead, the key challenge is controlling movement without drifting away from the worksite.
A multi‑arm robot can solve this by anchoring itself to nearby structures. For example, it could hold onto a frame or handrail with some arms while using others to manipulate tools or equipment. This approach mirrors strategies used in robotic manipulators designed for on‑orbit servicing and spacecraft maintenance.
Because of this, many space‑robotics concepts emphasize manipulator arms, grasping mechanisms, and precise control systems rather than traditional walking locomotion.
Early‑Stage Prototype Status
HELIOS is still an early prototype. Public information about detailed specifications—such as size, weight, lifting capacity, or total degrees of freedom—remains limited in currently available reports.
What is clear is that the robot is intended as a technology demonstrator exploring new ways for robots to move and work in microgravity. The project has been presented as part of a research effort focused on robotic assistants for future orbital operations.
Part of a Growing Space‑Robot Race
HELIOS appears at a time when space agencies and startups worldwide are accelerating efforts to develop robotic workers for orbit.
Several notable projects illustrate the trend:
NASA’s Robonaut 2 (R2)
NASA launched Robonaut 2 to the International Space Station in 2011 aboard Space Shuttle Discovery. It became the first humanoid robot in space, designed to assist astronauts and test how dexterous robots operate in orbit.
China’s PM01 robotic astronaut initiative
Chinese robotics company Engine AI has announced plans to send its PM01 humanoid robot into space as part of a “robot astronaut” exploration program, highlighting growing interest in autonomous robotic crew members for hazardous tasks.
Icarus Robotics’ “Joy” robot (ISS mission planned for 2027)
Startup Icarus Robotics is developing a free‑flying robot called Joy that is scheduled for testing aboard the International Space Station in early 2027. The mission will evaluate autonomous navigation and robotic operations in a real space‑station environment.
Together, these projects reflect a broader industry shift: robots are increasingly expected to handle inspection, repair, assembly, and logistics tasks in orbit, reducing risk for human astronauts.
The Bigger Idea Behind HELIOS
HELIOS illustrates how engineers are rethinking robotics for space rather than simply adapting Earth‑based designs. By abandoning legs and focusing on multi‑arm dexterity and anchoring, the robot’s structure directly matches the physics of microgravity.
If future versions mature beyond the prototype stage, robots like HELIOS could eventually help astronauts maintain spacecraft, assemble large orbital structures, and manage cargo operations—turning space stations into workplaces where humans and robots collaborate side by side.
frontiersin.org
A comprehensive survey of space robotic manipulators for ...