AnswersPublished22 sources
Hugging Face’s $399 Microduck Is a Trainable Robot Duck Built for Reinforcement Learning
Microduck is a 25 centimeter, under 800 gram bipedal robot for experimenting with reinforcement learning, not a general purpose home robot. Its software stack covers simulation, robot control, reinforcement learning training and sim to real deployment, while the assembled robot ships with seven trained behaviors suc...
Published byEdited with GPT-5.6 LunaImages generated with GPT Image 1.5
Research answer
Key takeaways
- Microduck is a 25 centimeter, under 800 gram bipedal robot for experimenting with reinforcement learning, not a general purpose home robot.
- Its software stack covers simulation, robot control, reinforcement learning training and sim to real deployment, while the assembled robot ships with seven trained behaviors such as walking, kicking and recovering fro...
- The key trade off is accessibility versus capability: the software is open and the price is far below specialist research hardware, but training reliable new behaviors still requires robotics, reinforcement learning a...
AI Prompt
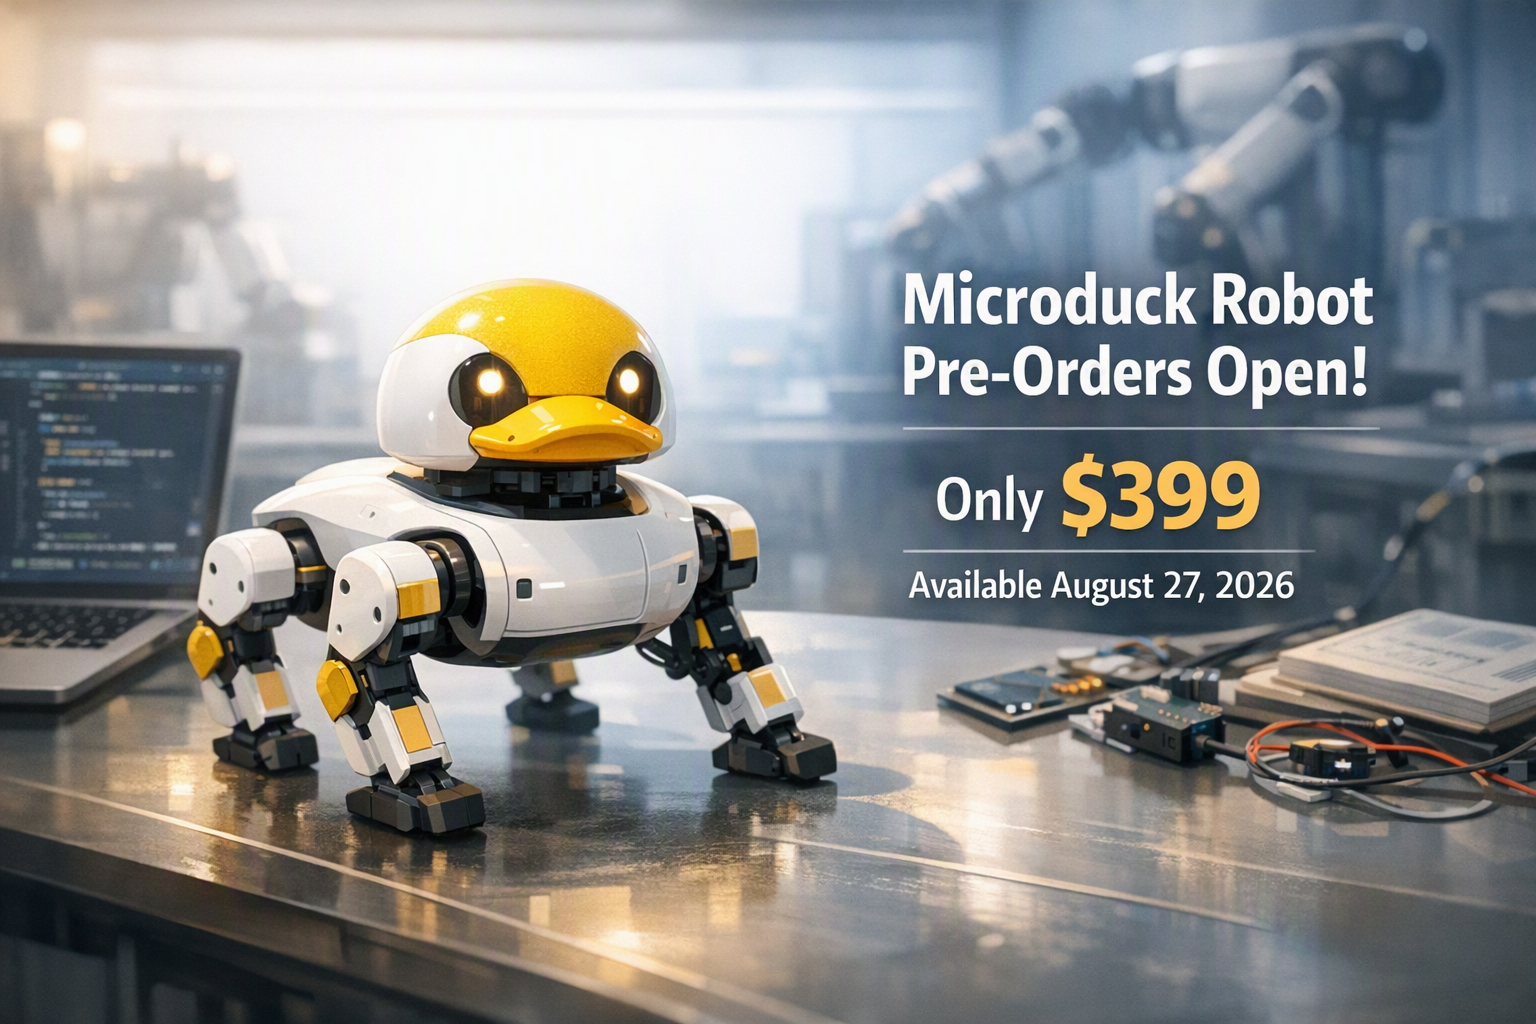
openai.comCreate a landscape editorial hero image for this Studio Global article: What is Hugging Face and Pollen Robotics’ Microduck robot, announced on August 27, 2026, including its $399 price and pre-order availability. Article summary: Microduck is a small, consumer-priced platform for learning and experimenting with legged-robot reinforcement learning—not a general-purpose home humanoid. Hugging Face and its Pollen Robotics team opened pre-orders on A. Topic tags: general, general web. Style: premium digital editorial illustration, source-backed research mood, clean composition, high detail, modern web publication hero. Use reference image context only for broad subject, composition, and topical grounding; do not copy the exact image. Avoid: logos, brand marks, copyrighted characters, real person likenesses, fake screenshots, UI text, readable text, watermarks, charts with fake numbers, clic
Microduck is Hugging Face and Pollen Robotics’ small, duck-shaped biped for learning how reinforcement-learning policies move a real robot. It stands 25 centimeters tall, weighs less than 800 grams and costs an introductory $399 before taxes and shipping. Pre-orders opened on August 27, 2026, but delivery expectations have already become less certain for new orders. 29
38
42
The important distinction is that Microduck is not being positioned as an autonomous household humanoid. It is a compact physical testbed: a robot that arrives with working behaviors, then lets developers train and deploy new ones through a public simulation and reinforcement-learning workflow.
What Microduck can do
Microduck has 15 motors, a camera, LiDAR, two inertial measurement units and an articulated beak for picking up small objects. Its onboard computer is listed as a Rockchip RK3566 system with an AI accelerator, 1 GB of RAM and 32 GB of storage. A removable battery is specified for roughly an hour of use, depending on activity. 29
32
The robot is intended to be playable immediately. It ships with seven trained moves, including walking or waddling, sitting, kicking, picking up objects, recovering from common falls and roller-skating. Those behaviors are neural policies rather than merely a collection of fixed animation clips. 20
21
29
That combination gives Microduck two audiences:
- Makers and curious users can operate the pre-trained behaviors with a controller.
- Robotics and machine-learning developers can inspect the software, modify training environments and attempt to transfer new behaviors to the physical robot.
How the sim-to-real pipeline works
The central idea is to train the robot in simulation before running the resulting policy on hardware. Microduck’s stack uses MuJoCo-based simulation and PPO reinforcement learning, then exports the trained policy to ONNX for onboard execution. The robot’s control loop runs at 50 Hz. 20
21
30
The difficult part is not making a simulated duck walk. It is making a policy survive the differences between a virtual robot and a physical one. The published approach therefore aims to make the simulated hardware less ideal by representing effects such as actuator behavior, friction, battery variation, command latency and mechanical play. It also uses randomized conditions so that the policy encounters a range of plausible robot states during training rather than memorizing one perfect simulation. 30
Backlash is especially important for a small biped. Gear play can mean that a commanded motor position does not immediately produce the expected movement at the joint. Modeling that gap—and accounting for where the physical encoder measures motion—exposes the policy to some of the errors it will face after deployment. The goal is a more reliable transfer from virtual training to the real robot, not a guarantee that every experiment will work on the first attempt. 30
The documented workflow is computationally heavier than the $399 price might suggest. Training examples use thousands of parallel simulated environments and CUDA-capable hardware; one reported walking-policy run takes roughly one to two hours under the project’s quick-start setup. Users without a suitable local GPU can submit training through Hugging Face Jobs. 20
21
What “open source” means here
Pollen describes the SDK, simulator and full reinforcement-learning stack as open and available under Apache 2.0. The project also publishes the policies and training materials needed to examine how the shipped behaviors work. 29
43
That openness is primarily about the software and learning pipeline. It does not mean that every mechanical and electronic design file for the commercial robot is necessarily available under the same license. Prospective buyers should therefore distinguish between an open software stack and an entirely open hardware product.
The distinction matters because Microduck’s value is less about customizing a shell than about reproducing the learning loop: define an environment, train a policy, export it and test the result on a real body.
Is Microduck easy for beginners?
The pre-trained behaviors make the robot approachable without requiring code on day one. Training a dependable new behavior is a different proposition. Users will need at least some familiarity with Python, reinforcement-learning concepts, reward design, simulation, robot dynamics and GPU-based training. They also need to test policies carefully on physical hardware, where falls, collisions and unexpected motor commands can damage the robot or nearby objects.
In practice, Microduck is best understood as an educational and experimental platform with a friendly industrial design—not as a plug-and-play robot that can learn any trick from a short natural-language instruction.
How the $399 price changes robotics experimentation
At $399 before taxes and shipping, Microduck makes a complete sim-to-real experiment far more accessible than buying a full-size research robot. The comparison should be treated as directional rather than a standardized market benchmark: Microduck is much smaller, less capable and designed for a narrower class of experiments.
The lower price also makes multi-robot work more plausible. Pollen has pointed to races, football and robots reacting to one another as possible community experiments. Several inexpensive robots can create learning scenarios that are difficult to reproduce with a single specialist research platform. 35
37
Where it fits in Hugging Face’s robotics strategy
Hugging Face acquired Pollen Robotics in April 2025 as part of its effort to connect open robotics hardware with its software and model-sharing ecosystem. Pollen’s existing lineup includes Reachy 2, a much larger research-oriented humanoid, while Reachy Mini targets expressive interaction, voice, vision and creative coding. 10
11
Microduck takes a different route. Its defining problems are locomotion, physical action, reinforcement learning and sim-to-real transfer. That makes it a small physical counterpart to the broader idea of sharing models: instead of sharing only a language or vision model, a community could share behaviors, environments and training recipes for the same robot body.
Price, colors and delivery
Microduck launched with four colorways: Cream, Graphite, Lavender and Sky. Pre-orders opened at $399 before taxes and shipping, with initial deliveries originally targeted for before Christmas 2026 in North America and Europe. 37
38
However, a later report said the company was no longer promising Christmas delivery for new orders and was showing an estimated four-to-six-month wait as it ramped production. Buyers should treat the original holiday timing as an initial target, not a guaranteed delivery date. 42
The clearest verdict is that Microduck is unusually affordable as a physical reinforcement-learning platform, but its appeal depends on what the buyer wants. Someone looking for a conversational home companion will likely find a limited 25-centimeter biped. Someone who wants to study how a learned behavior moves from MuJoCo simulation to a real robot gets a much more compelling proposition: a small, pre-trained machine with a public software pipeline and room for experimentation.
Studio Global AI
Continue your research
This page includes a source-backed answer you can continue inside Studio Global.
People also ask
What is the short answer to "Hugging Face’s $399 Microduck Is a Trainable Robot Duck Built for Reinforcement Learning"?
Microduck is a 25 centimeter, under 800 gram bipedal robot for experimenting with reinforcement learning, not a general purpose home robot.
What are the key points to validate first?
Microduck is a 25 centimeter, under 800 gram bipedal robot for experimenting with reinforcement learning, not a general purpose home robot. Its software stack covers simulation, robot control, reinforcement learning training and sim to real deployment, while the assembled robot ships with seven trained behaviors such as walking, kicking and recovering fro...
What should I do next in practice?
The key trade off is accessibility versus capability: the software is open and the price is far below specialist research hardware, but training reliable new behaviors still requires robotics, reinforcement learning a...
Sources
pollen-robotics.comMicroduck - A tiny biped robot you can teach new tricks
businessinsider.comHugging Face says sales for its robot ducks topped $2.6 million in 24 hours. Now there's a backlog.
ai-daily.devAI Daily Dev — August 18, 2026
marktechpost.com