AnswersPublished21 sources
Inside China’s Plan to Put Robot Dogs on the Moon
Chinese researchers from the China Academy of Space Technology (CAST) published a concept in the journal Chinese Space Science and Technology that envisions two quadruped robots working alongside a three astronaut cre... The concept breaks a 3 person lunar crew into specific roles: Astronaut 1 controls two robot dog...
Published byEdited with DeepSeek-V4-FlashImages generated with GPT Image 1.5
Research answer
Key takeaways
- Chinese researchers from the China Academy of Space Technology (CAST) published a concept in the journal Chinese Space Science and Technology that envisions two quadruped robots working alongside a three astronaut cre...
- The concept breaks a 3 person lunar crew into specific roles: Astronaut 1 controls two robot dogs for terrain scouting and hazard identification; Astronaut 2 collects samples and conducts science; Astronaut 3 coordina...
- This research stage blueprint fits into China’s phased ILRS strategy: robotic precursors (Chang’e 7 in H2 2026, Chang’e 8 in 2028), a crewed landing by 2030, and a basic permanently staffed south pole station by 2035...
AI Prompt
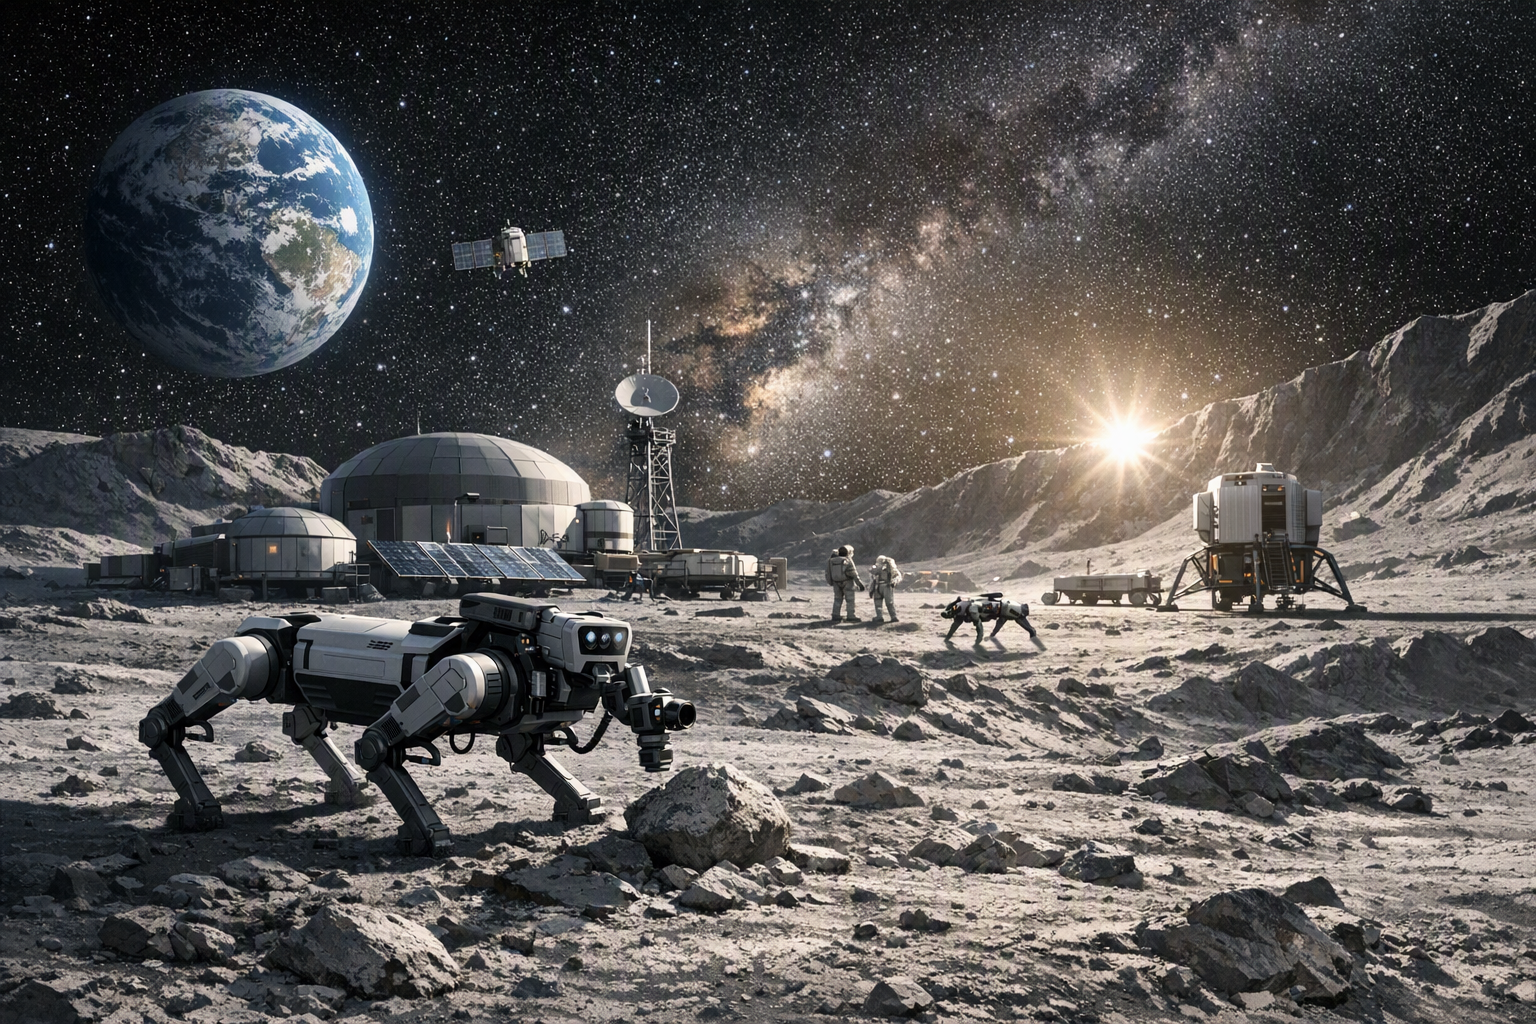
openai.comCreate a landscape editorial hero image for this Studio Global article: What is China's proposed plan for using robot dogs at its future International Lunar Research Station on the Moon's south pole, including th. Article summary: Chinese researchers from the China Academy of Space Technology (CAST) published a concept in the journal *Chinese Space Science and Technology* outlining how robot dogs could operate at the International Lunar Research S. Topic tags: general, general web, user generated, news. Style: premium digital editorial illustration, source-backed research mood, clean composition, high detail, modern web publication hero. Use reference image context only for broad subject, composition, and topical grounding; do not copy the exact image. Avoid: logos, brand marks, copyrighted characters, real person likenesses, fake screenshots, UI text, readable text, watermarks, charts w
Chinese researchers from the China Academy of Space Technology (CAST) have published a concept in the journal Chinese Space Science and Technology that outlines how quadruped robots — popularly called “robot dogs” — could operate at the International Lunar Research Station (ILRS) on the Moon’s south pole . The blueprint describes a three-astronaut team working alongside two intelligent machines, with roles ranging from terrain scouting and resource extraction to daily maintenance and even emotional support for the crew .
Studio Global AI
Continue your research
This page includes a source-backed answer you can continue inside Studio Global.
People also ask
What is the short answer to "Inside China’s Plan to Put Robot Dogs on the Moon"?
Chinese researchers from the China Academy of Space Technology (CAST) published a concept in the journal Chinese Space Science and Technology that envisions two quadruped robots working alongside a three astronaut cre...
What are the key points to validate first?
Chinese researchers from the China Academy of Space Technology (CAST) published a concept in the journal Chinese Space Science and Technology that envisions two quadruped robots working alongside a three astronaut cre... The concept breaks a 3 person lunar crew into specific roles: Astronaut 1 controls two robot dogs for terrain scouting and hazard identification; Astronaut 2 collects samples and conducts science; Astronaut 3 coordina...
What should I do next in practice?
This research stage blueprint fits into China’s phased ILRS strategy: robotic precursors (Chang’e 7 in H2 2026, Chang’e 8 in 2028), a crewed landing by 2030, and a basic permanently staffed south pole station by 2035...
Sources
scmp.comChina’s lunar research station could be guarded by robot watchdogs: scientists
news24online.comChina's moon base plan: Robot dogs could soon patrol the ...
interestingengineering.comChina's 2035 moon base could see robot dogs patrol, build ...
gadgetreview.comChina Wants Robot Dogs to Help Build Its Moon Base by 2035