AnswersPublished15 sources
What happened during Lexiang Technology (also known as JoyIn Technology)’s September 16, 2026 public Aether embodied-model stress test in Shanghai’s Minhang district, including the model’s approximate size, training data, technical approach, cross-embodiment capabilities, the rol
On September 16 in Shanghai’s Minhang district, Lexiang/JoyIn publicly streamed an outdoor barbecue-service test lasting more than an hour, presenting it as a real-world stress test of its Aether embodied model rather than a polished, pre-scripted demo. The evidence supports that Aether controlled r On September 16...
Published byEdited with GPT-5.6 TerraImages generated with GPT Image 2
Research answer
Key takeaways
- On September 16 in Shanghai’s Minhang district, Lexiang/JoyIn publicly streamed an outdoor barbecue-service test lasting more than an hour, presenting it as a real-world stress test of its Aether embodied model rather than a polished, pre-scripted demo. The evidence supports that Aether controlled r
- On September 16 in Shanghai’s Minhang district, Lexiang/JoyIn publicly streamed an outdoor barbecue-service test lasting more than an hour, presenting it as a real-world stress test of its Aether embodied model rather than a polished, pre-scripted demo. The evidence supports that
- **Model and training claim:** JoyIn describes Aether as an approximately 4-billion-parameter embodied foundation model trained on about 200 hours of human video and “zero” real-robot training data. Its stated approach is perception/action-oriented physical interaction rather than
AI Prompt
openai.comCreate a landscape editorial hero image for this Studio Global article: What happened during Lexiang Technology (also known as JoyIn Technology)’s September 16, 2026 public Aether embodied model stress test in Sh. Article summary: On September 16 in Shanghai’s Minhang district, Lexiang/JoyIn publicly streamed an outdoor barbecue service test lasting more than an hour, presenting it as a real world stress test of its Aether embodied model rather th. Topic tags: general web, openai, agents, ai, automation. Style: premium digital editorial illustration, source-backed research mood, clean composition, high detail, modern web publication hero. Use reference image context only for broad subject, composition, and topical grounding; do not copy the exact image. Avoid: logos, brand marks, copyrighted characters, real person likenesses, fake screenshots, UI text, readable text, watermarks, charts
On September 16 in Shanghai’s Minhang district, Lexiang/JoyIn publicly streamed an outdoor barbecue-service test lasting more than an hour, presenting it as a real-world stress test of its Aether embodied model rather than a polished, pre-scripted demo. The evidence supports that Aether controlled robots through a sustained service workflow; it does not yet independently establish the company’s broader performance or generalization claims. 12
15
Model and training claim: JoyIn describes Aether as an approximately 4-billion-parameter embodied foundation model trained on about 200 hours of human video and “zero” real-robot training data. Its stated approach is perception/action-oriented physical interaction rather than a text-first system. These are company claims, not independently audited results.
7
15
Cross-embodiment claim: The company calls Aether a cross-embodiment general model—one policy intended to work across differing robot bodies rather than requiring a separately trained model for each machine. Before the barbecue event, it drew attention with a claimed 10-minute, uncut, single-take video showing coordinated work across different embodiments.
10
13
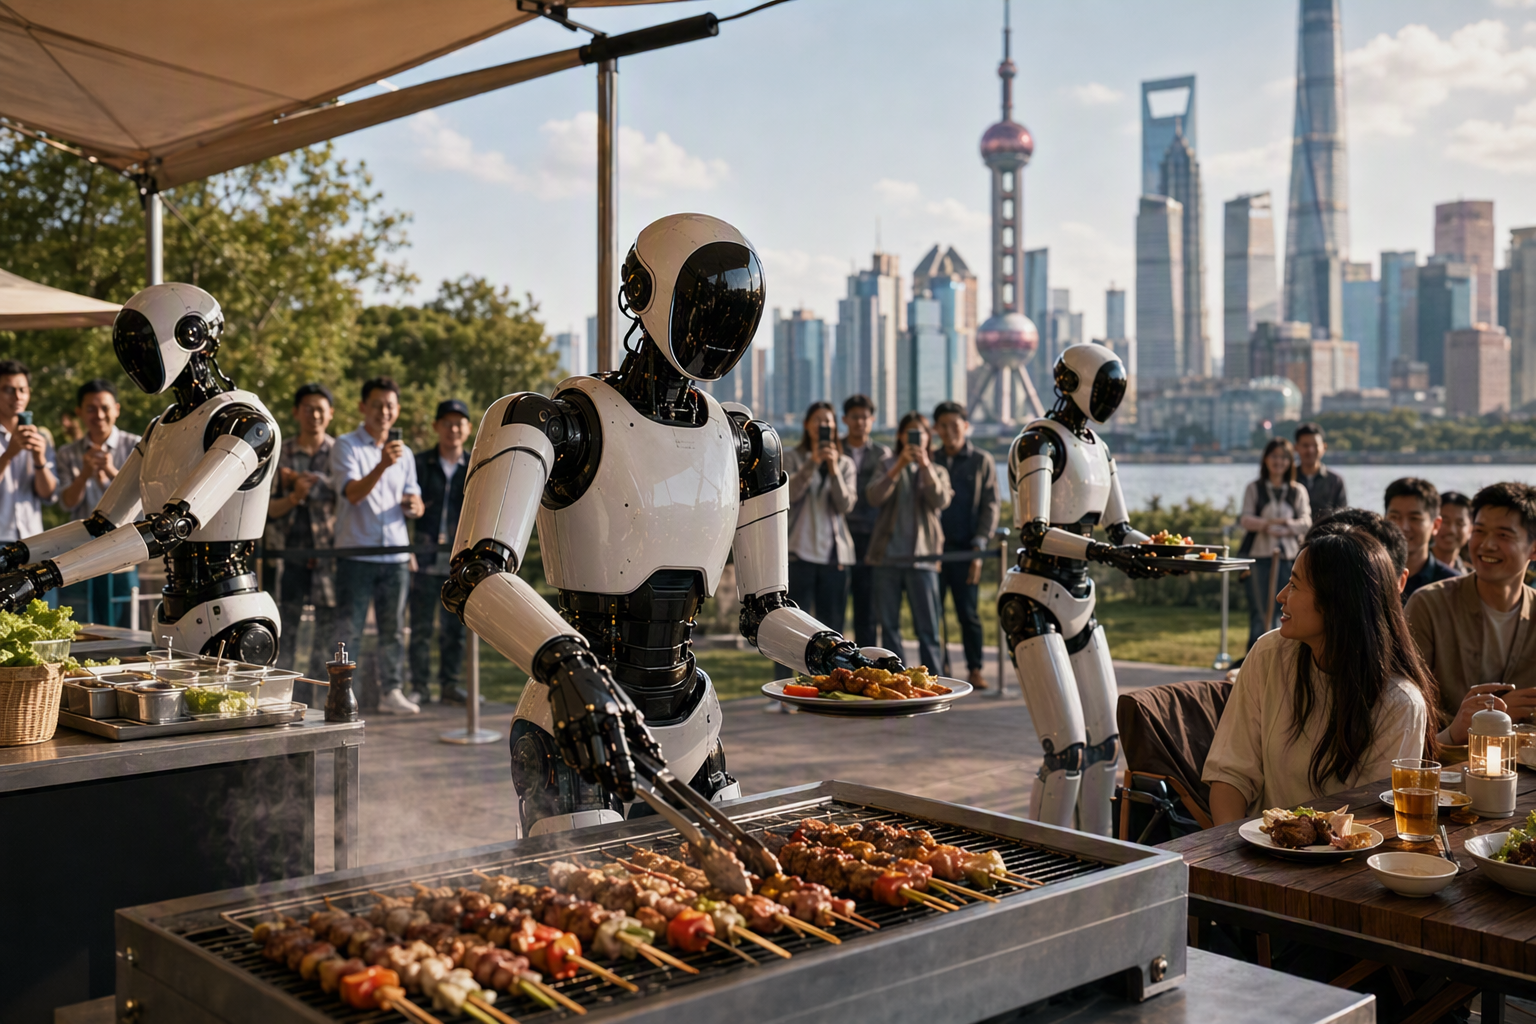
What the robots did: Reporting describes a grill robot remaining at the barbecue station and cooking skewers, while service robots took orders, carried food, served customers, and interacted with them. The coordination highlight was a handoff: the grill robot passed finished food to a service robot, which brought it to a table. One service robot reportedly interrupted its current activity to fetch water when asked; others displayed more direct or more procedure-bound behavior.
12
Why it was harder than a studio demo: The test was outdoors and open to real-time customer requests, interruption, changing objects and people, uneven environmental conditions, and a multi-step task chain—ordering, cooking, handoff, delivery, and interaction. Lexiang said it involved no rehearsal, preset script, or teleoperation; those autonomy conditions should be treated as assertions unless independently verified from full telemetry and operational logs.
What it establishes: A public, extended livestream is meaningful evidence that the demonstrated system could sustain some multi-robot food-service behavior in a less controlled setting than a short studio clip. It also makes failures, stalls, and recovery behavior more observable than edited footage.
What it does not establish: There is insufficient evidence to conclude that Aether is broadly robust, truly zero-shot across hardware, reliably autonomous without human intervention, or superior to competing embodied models. A reproducible technical report would need model architecture and interfaces, data provenance, hardware/control-stack details, intervention logs, failure rates, task definitions, held-out tests, and independent benchmark comparisons. None is supplied in the available reporting.
Studio Global AI
Continue your research
This page includes a source-backed answer you can continue inside Studio Global.
People also ask
What is the short answer to "What happened during Lexiang Technology (also known as JoyIn Technology)’s September 16, 2026 public Aether embodied-model stress test in Shanghai’s Minhang district, including the model’s approximate size, training data, technical approach, cross-embodiment capabilities, the rol"?
On September 16 in Shanghai’s Minhang district, Lexiang/JoyIn publicly streamed an outdoor barbecue-service test lasting more than an hour, presenting it as a real-world stress test of its Aether embodied model rather than a polished, pre-scripted demo. The evidence supports that Aether controlled r
What are the key points to validate first?
On September 16 in Shanghai’s Minhang district, Lexiang/JoyIn publicly streamed an outdoor barbecue-service test lasting more than an hour, presenting it as a real-world stress test of its Aether embodied model rather than a polished, pre-scripted demo. The evidence supports that Aether controlled r On September 16 in Shanghai’s Minhang district, Lexiang/JoyIn publicly streamed an outdoor barbecue-service test lasting more than an hour, presenting it as a real-world stress test of its Aether embodied model rather than a polished, pre-scripted demo. The evidence supports that
What should I do next in practice?
**Model and training claim:** JoyIn describes Aether as an approximately 4-billion-parameter embodied foundation model trained on about 200 hours of human video and “zero” real-robot training data. Its stated approach is perception/action-oriented physical interaction rather than