AnswersPublished16 sources
BG-5 Golden Dragon Fish: What Boyagongdao Demonstrated at CIFTIS 2026
Boyagongdao’s BG 5 demonstration at CIFTIS 2026 showed a propeller free robotic fish that uses a three joint, seven segment tail and onboard obstacle sensing to adjust its route autonomously. The roughly 640 mm long, 3 kg vehicle is positioned for shallow water inspection and biomimetic robotics research, while the...
Published byEdited with GPT-5.6 TerraImages generated with GPT Image 2
Research answer
Key takeaways
- Boyagongdao’s BG 5 demonstration at CIFTIS 2026 showed a propeller free robotic fish that uses a three joint, seven segment tail and onboard obstacle sensing to adjust its route autonomously.
- The roughly 640 mm long, 3 kg vehicle is positioned for shallow water inspection and biomimetic robotics research, while the BG 5V variant is intended for experiments in multi robot path planning, task allocation, and...
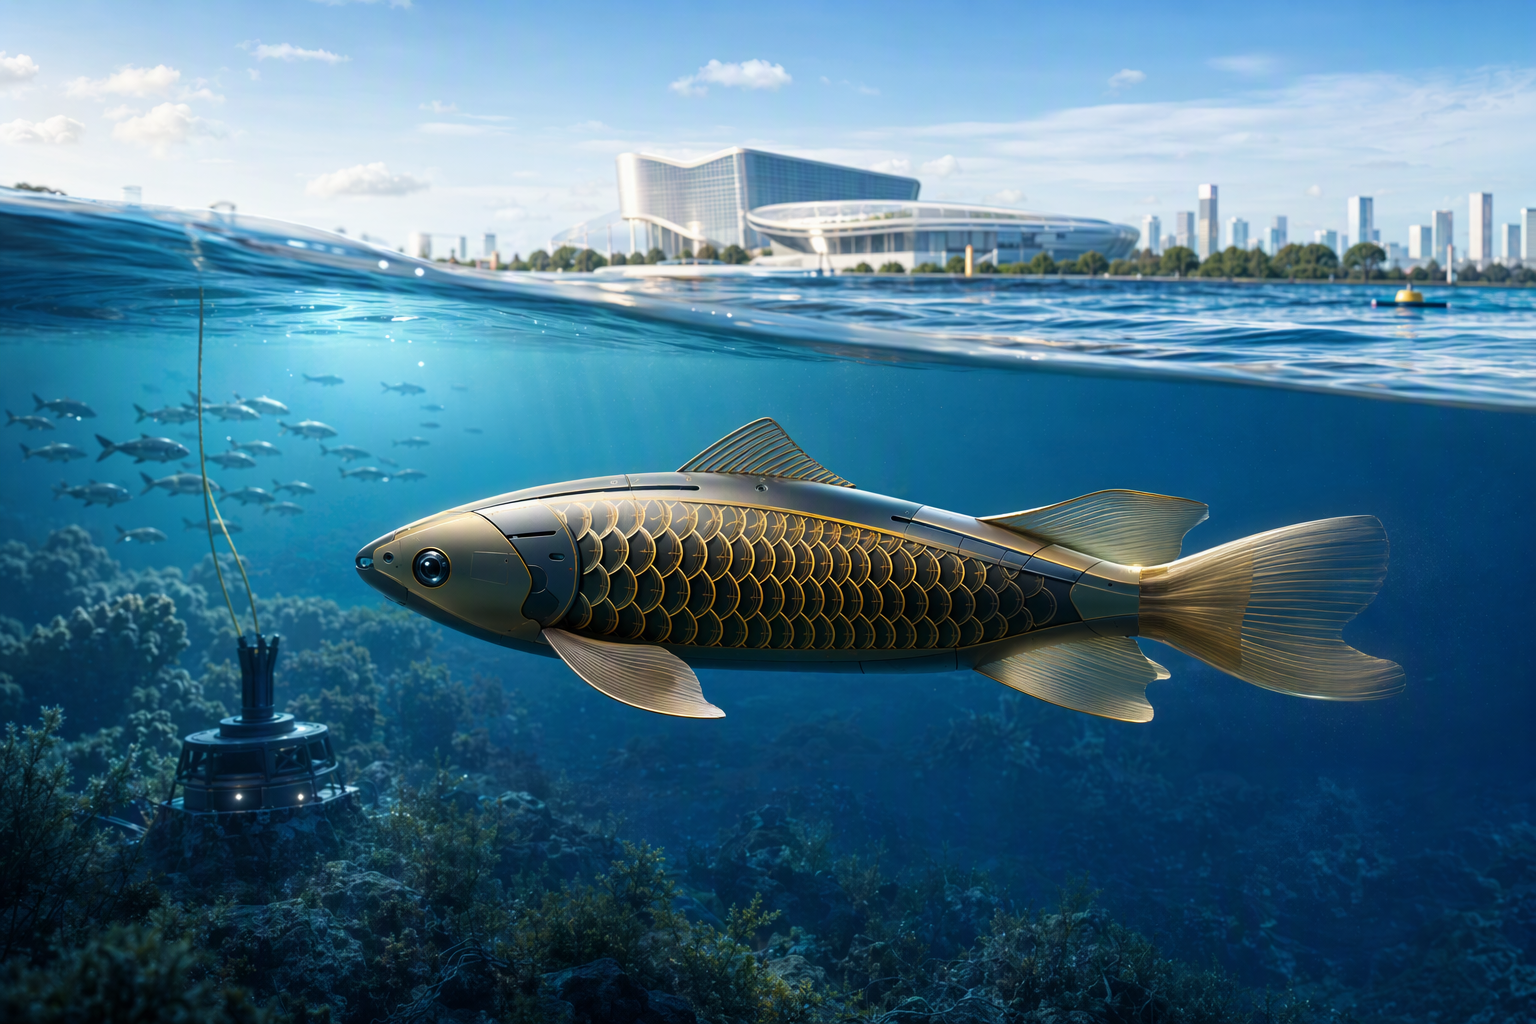
AI Prompt
openai.comCreate a landscape editorial hero image for this Studio Global article: What did Boyagongdao demonstrate with its BG-5 Golden Dragon Fish biomimetic autonomous underwater vehicle at the 2026 China International F. Article summary: At CIFTIS 2026 in Beijing, Boyagongdao presented the BG-5 Golden Dragon Fish as a small, propeller-free biomimetic AUV that imitates a golden arowana’s swimming rather than following a fixed, pre-programmed course. It de. Topic tags: general, general web, academic, education. Style: premium digital editorial illustration, source-backed research mood, clean composition, high detail, modern web publication hero. Use reference image context only for broad subject, composition, and topical grounding; do not copy the exact image. Avoid: logos, brand marks, copyrighted characters, real person likenesses, fake screenshots, UI text, readable text, watermarks, charts wi
Boyagongdao used the 2026 China International Fair for Trade in Services (CIFTIS) in Beijing to showcase the BG-5 Golden Dragon Fish, a compact biomimetic autonomous underwater vehicle (AUV) modeled on the swimming motion of a golden arowana. The key demonstration was not simply fish-like appearance: the vehicle was presented as detecting obstacles and adapting its route rather than traveling only along a fixed, pre-programmed path. 4
8
A propeller-free fish robot
Instead of a conventional rotating propeller, the BG-5 moves with a flexible, multi-joint tail. Reports describe the tail as having three joints divided into seven segments, producing thrust through a traveling, wave-like motion. 5
That design is central to the vehicle’s biomimetic approach. Its body and tail aim to reproduce fish locomotion while retaining autonomous navigation functions, rather than using the more familiar form factor of a small propeller-driven underwater drone. 4
6
What the CIFTIS display showed
At the Beijing event, Boyagongdao presented the BG-5 as a vehicle capable of sensing obstacles and autonomously changing course. According to exhibition reporting, its onboard sensors allow it to plan movement around obstacles instead of relying exclusively on a predetermined route. 4
8
The available reporting supports a demonstration of fish-like locomotion and autonomous obstacle avoidance. It does not establish performance benchmarks for endurance, localization accuracy, navigation accuracy, acoustic signature, payload capacity, or operation in conditions such as strong currents, turbid water, dense vegetation, tunnels, or working hydropower facilities.
Listed BG-5 specifications
The reported figures below are catalogue or manufacturer-listed specifications, rather than independently measured test results:
- Dimensions: 640 × 204 × 90 mm
5
- Mass: about 3 kg
- Maximum speed: 0.6 m/s
- Maximum operating depth: 5 m
- Propulsion: three-joint, seven-segment traveling-wave tail rather than a conventional propeller
Those numbers indicate a small shallow-water platform, not a deep-diving AUV. The 5 m depth rating in particular defines the currently reported operating envelope. 5
Intended uses and the BG-5V research platform
Reporting around the exhibit describes the BG-5 as a potential platform for shallow-water inspection, including hydropower-related work, as well as research and educational applications involving fish-inspired locomotion. 6
13
Boyagongdao also lists a BG-5V configuration that combines the robotic fish with a software platform for multi-robot experiments. The listed research functions include global and local path planning, task allocation, formation control, cooperative transport, and other coordinated group tasks. 12
A compact, propeller-free vehicle could be useful to investigate navigation in confined or cluttered water where maneuverability and avoiding propeller contact are important considerations. But that is a design rationale, not proof that the BG-5 has already outperformed conventional underwater vehicles in real inspection environments.
What remains to be validated
The CIFTIS appearance demonstrated a distinctive combination of biomimetic propulsion and autonomous route adjustment. It did not provide independent evidence about mission duration, underwater communications reliability, noise levels, payload limits, or navigation precision.
As a result, the BG-5’s quoted 0.6 m/s top speed and 5 m depth should be read as rated specifications. Its practical value for hydropower inspection, cluttered-water navigation, or coordinated multi-robot missions will depend on validation in the actual conditions, mission lengths, and sensing environments where it is deployed. 5
12
Studio Global AI
Continue your research
This page includes a source-backed answer you can continue inside Studio Global.
People also ask
What is the short answer to "BG-5 Golden Dragon Fish: What Boyagongdao Demonstrated at CIFTIS 2026"?
Boyagongdao’s BG 5 demonstration at CIFTIS 2026 showed a propeller free robotic fish that uses a three joint, seven segment tail and onboard obstacle sensing to adjust its route autonomously.
What are the key points to validate first?
Boyagongdao’s BG 5 demonstration at CIFTIS 2026 showed a propeller free robotic fish that uses a three joint, seven segment tail and onboard obstacle sensing to adjust its route autonomously. The roughly 640 mm long, 3 kg vehicle is positioned for shallow water inspection and biomimetic robotics research, while the BG 5V variant is intended for experiments in multi robot path planning, task allocation, and...
Sources
timesofindia.indiatimes.comWatch: China unveils robotic fish modelled on the golden ...
bolnews.comChina unveils ‘Golden Dragon Fish’ robot, sparking buzz over ...
thearabianpost.comAsia Focus: In-depth coverage of Asian affairs