AnswersPublished30 sources
How Hyundai’s RMAC Trains Atlas Humanoids for Automotive Logistics
Hyundai’s RMAC near Savannah is a training and validation hub where Atlas learns automotive parts sequencing before planned production floor operations at HMGMA in 2028. Atlas combines autonomous perception and manipulation with human operated VR or tablet controls for guidance and data collection; reinforcement lea...
Published byEdited with GPT-5.6 TerraImages generated with GPT Image 2
Research answer
Key takeaways
- Hyundai’s RMAC near Savannah is a training and validation hub where Atlas learns automotive parts sequencing before planned production floor operations at HMGMA in 2028.
- Atlas combines autonomous perception and manipulation with human operated VR or tablet controls for guidance and data collection; reinforcement learning in simulation helps it adapt to variation before real world vali...
- Parts sequencing is a deliberately bounded first use case, but it still requires reliable perception, grasping, whole body control and integration with factory workflows.[10][12]
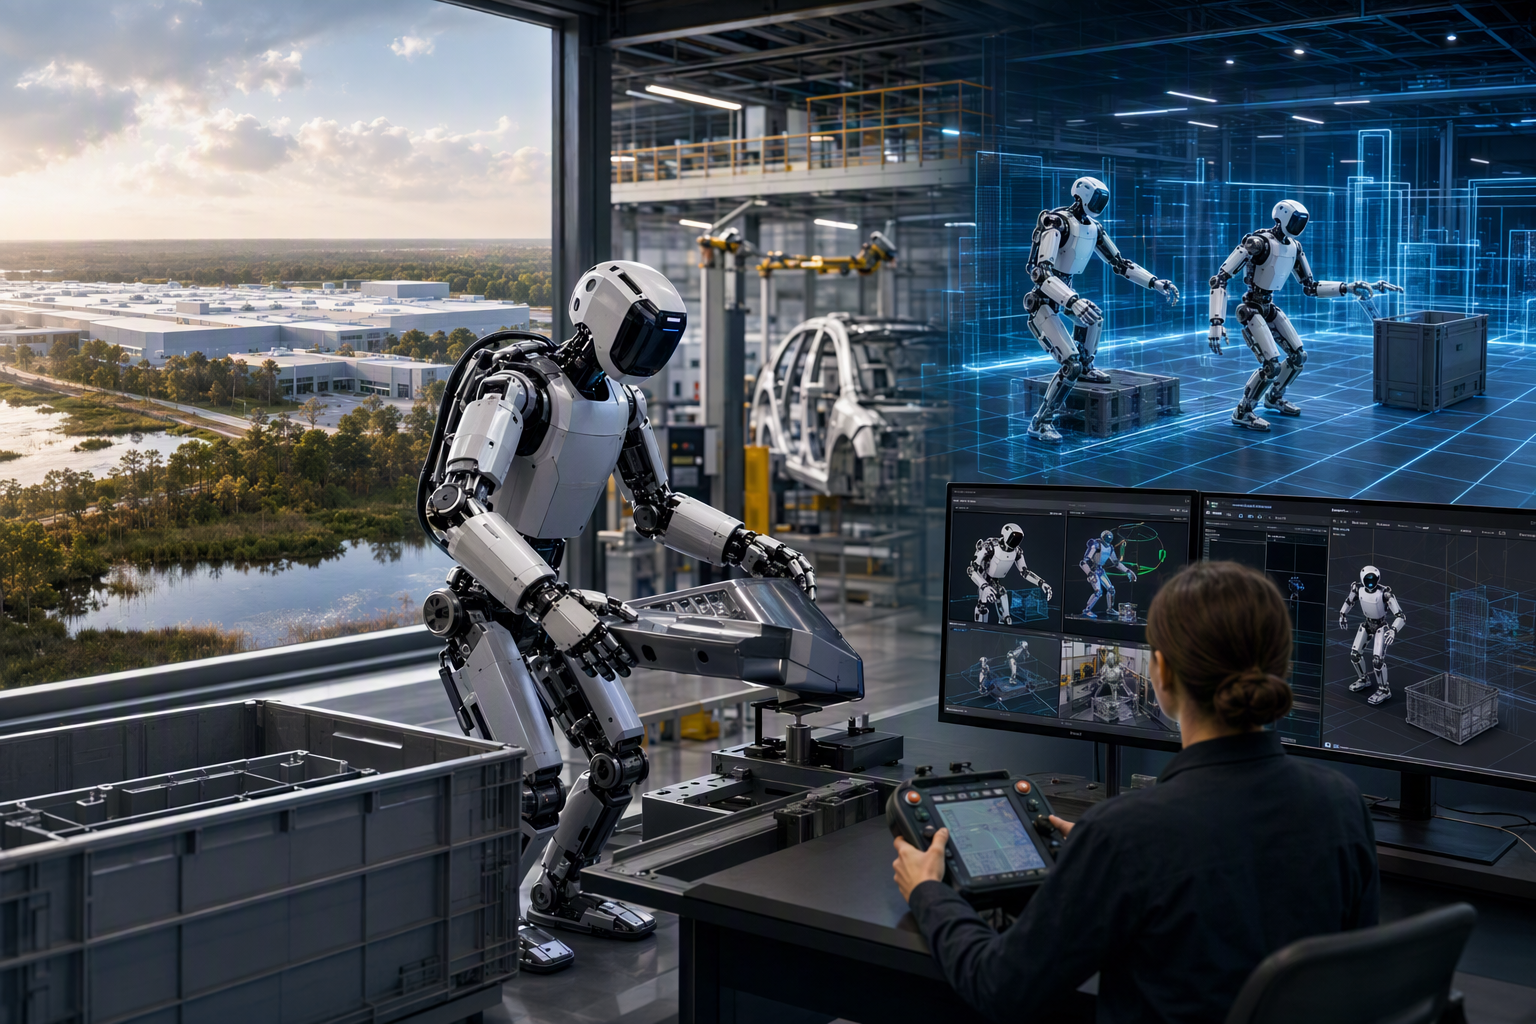
AI Prompt
openai.comCreate a landscape editorial hero image for this Studio Global article: How is Boston Dynamics’ new Robotics Metaplant Application Center at Hyundai Motor Group Metaplant America near Savannah training Atlas huma. Article summary: RMAC is intended to turn Atlas from a promising humanoid demonstration into a repeatable industrial system: operators teach task fragments, simulation expands the range of situations the robot can handle, and the resulti. Topic tags: general, general web. Style: premium digital editorial illustration, source-backed research mood, clean composition, high detail, modern web publication hero. Use reference image context only for broad subject, composition, and topical grounding; do not copy the exact image. Avoid: logos, brand marks, copyrighted characters, real person likenesses, fake screenshots, UI text, readable text, watermarks, charts with fake numbers, clic
RMAC—the Robotics Metaplant Application Center at Hyundai Motor Group Metaplant America in Georgia—is designed to bridge the gap between a capable humanoid robot and a dependable factory workflow. Boston Dynamics and Hyundai are beginning with automotive parts logistics and sequencing, then validating Atlas behaviors in production-like conditions before broader deployment.35
36
What Atlas is learning at RMAC
The initial assignment is parts sequencing: preparing the correct components in the correct order for vehicles moving down a mixed-model assembly line. It is a common automotive logistics task and a useful first target because it has clear business value while remaining more bounded than full assembly work.10
A demonstrated version of the task has Atlas autonomously move engine covers from supplier containers to a mobile sequencing dolly. The robot receives bin-location information, uses machine-learning vision to localize bins and fixtures, applies a grasping policy, and continually estimates the state of the object it is handling.9
At RMAC, Hyundai describes robots learning human collaboration by mapping movements such as lifts, turns and recoveries into training for repetitive and complex tasks. The center also collects behavioral data, tests systems and verifies them before commercial production use.36
42
The training stack: human guidance, simulation and validation
Atlas is not trained through one technique alone. The practical approach combines three complementary layers.
1. Human-guided demonstrations and remote control
Atlas can operate autonomously, but Boston Dynamics says it can also be manually controlled with a VR headset or tablet controller. These interfaces give operators a way to demonstrate motions, intervene when a task is unfamiliar, and generate useful examples for behavior development rather than requiring every motion to be scripted by hand.4
This is especially valuable for manipulation work, where a successful action depends on the robot’s posture, object contact and the particular layout of the cell.
2. Reinforcement learning in simulation
Boston Dynamics has described training Atlas for heavy-object handling by exposing it to an extremely large number of simulated variations. In its refrigerator-lifting example, the robot must adapt to differences it may encounter in the real world rather than simply reproduce a fixed motion.5
That matters in automotive logistics because the relevant variation is not limited to the part itself. Bins, fixtures, object poses and operating conditions can change. Simulation lets the team broaden the range of cases a policy experiences before deploying it on physical hardware.
3. Realistic factory validation
Simulation is useful, but the final test is whether the behavior works reliably in a manufacturing environment. RMAC is intended to provide that validation stage: a place to develop use cases, collect data, test performance and refine robot behavior before Atlas is introduced on Hyundai production lines.36
42
Why automotive “pick and place” remains difficult
Moving a component from one container to another sounds simple. In a real factory, it is a mobile-manipulation problem with several hard requirements operating at once.
- Perception must be contextual. Atlas needs to understand both object geometry and the role of an object in its environment. Boston Dynamics notes that shiny metallic or low-contrast dark factory parts can be difficult to identify, even in an apparently simple pick-and-place task.
12
- Grasping is not enough. Heavy or awkward objects require the robot to account for mass and inertia, brace where appropriate and use whole-body control rather than relying on its hands alone.
- Tasks are long sequences, not isolated motions. A robot may need to interpret a work order, locate a bin, identify the correct component, pick it safely, move it to its destination, place it precisely and handle changes or failures. Boston Dynamics is developing language-conditioned Large Behavior Models for these long-horizon manipulation tasks.
- Factory integration matters. Atlas is designed to support barcode scanning and workflow integrations, but manufacturing use also demands predictable execution and limited supervision—not merely a successful run in a controlled demo.
From isolated trials to a reusable behavior pipeline
The important shift behind RMAC is organizational as well as technical. Earlier Atlas demonstrations showed individual capabilities. RMAC is built as a standing system for creating, evaluating and transferring behaviors: collect operational data, develop and test a behavior, validate it in a realistic environment, then reuse it.
Boston Dynamics says a new skill learned by one Atlas can be deployed across an Atlas fleet, and that tasks can be customized and redeployed at scale.1
6 Hyundai similarly describes RMAC as part of an end-to-end AI robotics value chain that combines training data with testing and verification.
36
That does not mean every behavior will transfer unchanged between plants. But it changes the target from a bespoke, site-by-site experiment to a repeatable package of robot capability that can be improved over time.
What the deployment roadmap says
RMAC began full-scale operations in September 2026 after a pilot period, serving as a testbed before Atlas is deployed to Hyundai manufacturing sites.33
35
Hyundai’s published roadmap separates the training period from production-floor operations: Atlas is expected to begin operations at HMGMA in 2028, initially focused on parts sequencing. Reporting on Hyundai’s plans points to a phased expansion to other sites and eventually to component assembly work.26
44
Hyundai has also communicated an ambition to deploy more than 25,000 Atlas robots across Hyundai and Kia plants and to reach annual production capacity of about 30,000 robots by 2028. Those are stated plans and capacity targets, not evidence of an installed fleet today.26
27
Could Atlas move to Hyundai’s Czech plant?
Hyundai Motor Manufacturing Czech in Nošovice is discussing possible Atlas deployment with Boston Dynamics and Hyundai headquarters, according to recent reporting. No date for testing on active production lines—or for a production rollout—has been announced.18
19
A European trial would test more than robot capability. Reporting identifies labor shortages as part of the rationale, while workforce acceptance, safety, quality and integration into existing work processes are central questions for any deployment.19
21
The near-term conclusion is straightforward: Georgia is the main training ground, parts sequencing is the first practical application, and RMAC’s success will be measured by whether Atlas behaviors become reliably repeatable in real factory operations—not by demonstrations alone.
Studio Global AI
Continue your research
This page includes a source-backed answer you can continue inside Studio Global.
People also ask
What is the short answer to "How Hyundai’s RMAC Trains Atlas Humanoids for Automotive Logistics"?
Hyundai’s RMAC near Savannah is a training and validation hub where Atlas learns automotive parts sequencing before planned production floor operations at HMGMA in 2028.
What are the key points to validate first?
Hyundai’s RMAC near Savannah is a training and validation hub where Atlas learns automotive parts sequencing before planned production floor operations at HMGMA in 2028. Atlas combines autonomous perception and manipulation with human operated VR or tablet controls for guidance and data collection; reinforcement learning in simulation helps it adapt to variation before real world vali...
What should I do next in practice?
Parts sequencing is a deliberately bounded first use case, but it still requires reliable perception, grasping, whole body control and integration with factory workflows.[10][12]