AnswersPublished20 sources
How Humanoid Robots Were Tested on Hotel Work at the World Humanoid Robot Games
At the second World Humanoid Robot Games, hotel robots had 30 minutes to move luggage, restock a guest room and tidy a bed. The challenge combined heavy load balance, grasping, navigation, obstacle avoidance and long chain planning in a real hotel environment—not isolated laboratory motions.
Published byEdited with GPT-5.6 LunaImages generated with GPT Image 1.5
Research answer
Key takeaways
- At the second World Humanoid Robot Games, hotel robots had 30 minutes to move luggage, restock a guest room and tidy a bed.
- The challenge combined heavy load balance, grasping, navigation, obstacle avoidance and long chain planning in a real hotel environment—not isolated laboratory motions.
- Soft bedding, narrow corridors, clutter and shifting loads exposed the gap between a convincing robot demonstration and dependable commercial service.
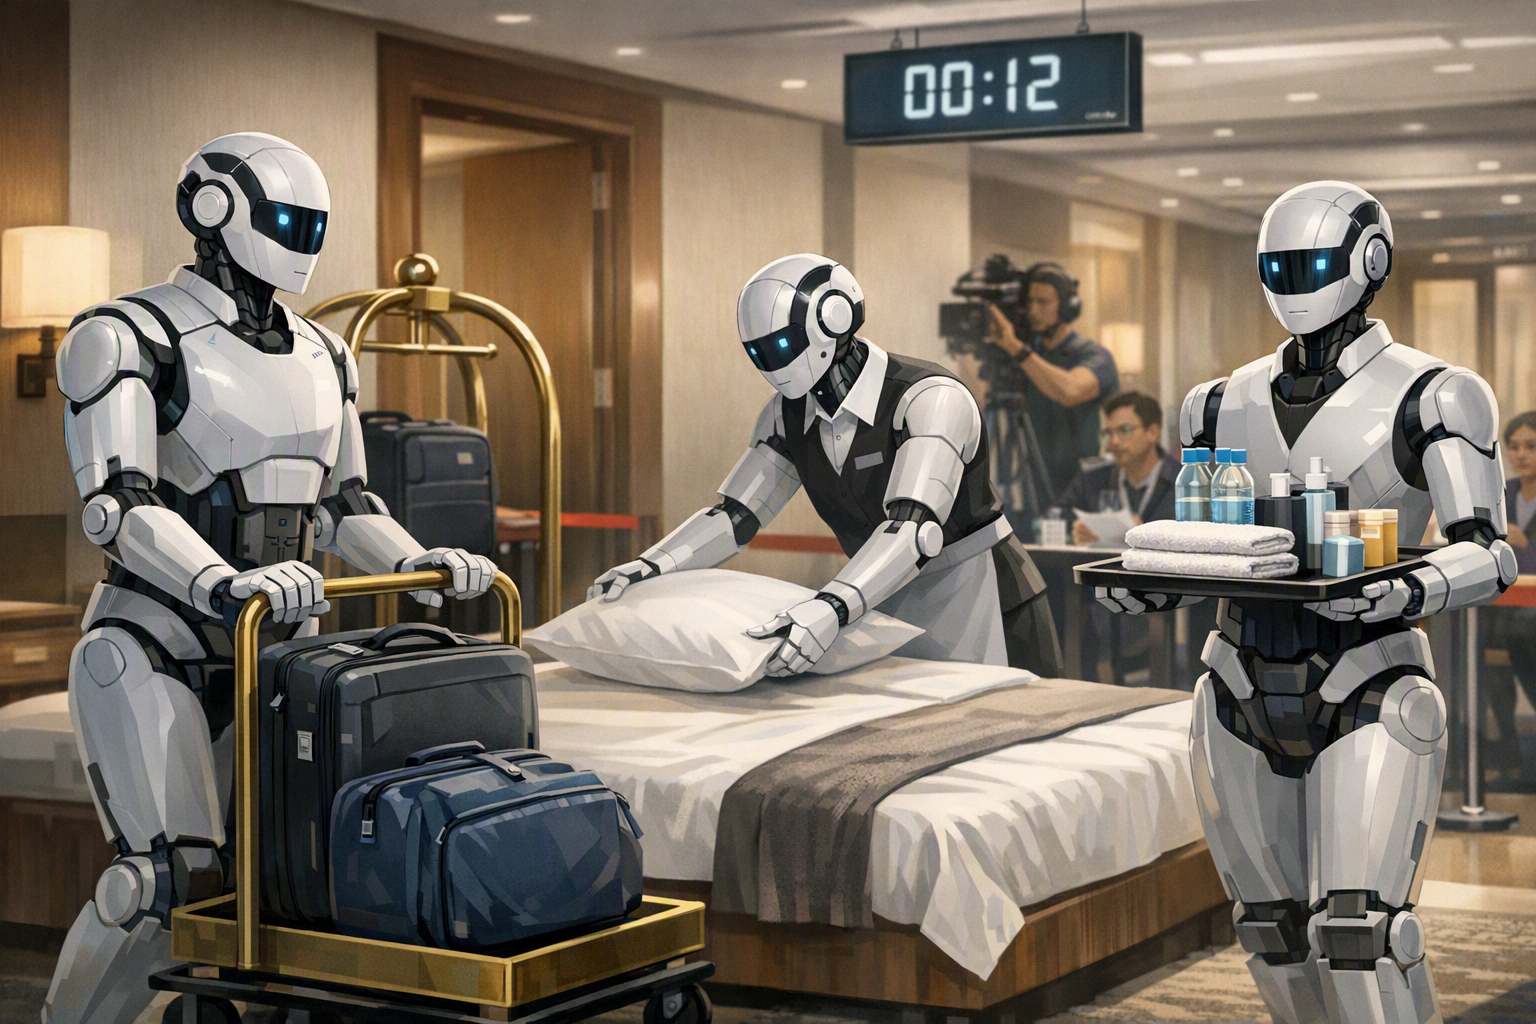
AI Prompt
openai.comCreate a landscape editorial hero image for this Studio Global article: How did the hotel guest service competition at the second World Humanoid Robot Games, held at Beijing Wuzhou Hotel on August 16–17, 2026, te. Article summary: The hotel event was a compressed, work-like test rather than a demonstration: within 30 minutes, humanoids had to move luggage, replenish rooms, and tidy beds in an operating-style hotel environment. It tested whether ro. Topic tags: general, general web, user generated, news. Style: premium digital editorial illustration, source-backed research mood, clean composition, high detail, modern web publication hero. Use reference image context only for broad subject, composition, and topical grounding; do not copy the exact image. Avoid: logos, brand marks, copyrighted characters, real person likenesses, fake screenshots, UI text, readable text, watermarks, charts w
The hotel competition was designed as a compressed work shift, not a stage demonstration. Within 30 minutes, humanoid robots had to complete three connected assignments—luggage handling, guest-room restocking and housekeeping—in a realistic hotel environment. Judges considered completed tasks, collisions and the smoothness of operation, so speed alone was not enough. 10
11
What the three tasks required
1. Luggage handling
Robots had to handle suitcases of different sizes, place luggage on a transport cart and push the loaded cart to a designated room. 10
13 That sequence tested more than a robot’s ability to pick up an object. It required:
- recognizing and grasping differently shaped luggage;
- maintaining balance while carrying a load;
- coordinating the whole body while pushing a cart;
- navigating hotel corridors and avoiding obstacles; and
- linking several actions into one uninterrupted workflow.
The task brought together perception, dexterous manipulation, locomotion, payload-bearing balance and collision-free navigation. 11
13
2. Room restocking
The restocking stage required robots to collect supplies—including clean towels, slippers and bottled water—and put them in the appropriate places in a guest room. 3
10
27 This tested object recognition and fine manipulation, but also the ability to remember the task sequence, move between service areas and rooms, and place each item correctly.
That combination is important in a hotel. A robot can perform a single grasp in a controlled setting yet still fail when it must identify several objects, carry them through a constrained space and complete a series of dependent actions without losing track of the job.
3. Bed tidying
For housekeeping, robots cleared used linen and waste before making the bed. 3
10
27 Bedding and towels are substantially harder to manipulate than rigid objects because they deform, fold unpredictably and change shape as they are lifted or pulled.
A successful run therefore depends on visual perception, adaptable grasping, contact control and planning that can respond to changing material shapes. Pre-programmed movements are less reliable when a sheet or towel does not lie exactly where the robot expects it to be.
Why a real hotel made the test harder
The setting introduced constraints that are easy to remove in a laboratory. Narrow corridors limit turning space and leave less room to recover from an error. Guest rooms add clutter and variable object positions. A suitcase or loaded cart changes the robot’s center of mass, making posture control and whole-machine stability more difficult.
The robot also had to coordinate several capabilities at once: seeing the environment, choosing a route, grasping objects, maintaining balance, avoiding collisions and deciding what to do next. The challenge was not simply whether each motion was possible, but whether the full chain could be executed safely and smoothly under a time limit. 4
11
13
Autonomy was part of the result
The scoring system explicitly separated autonomous work from teleoperation. In scenario-based events, a fully autonomous completion received a weighting of 1.0, while a remotely controlled completion received 0.5. 5
11
13
That rule changes what teams must optimize for. A remote operator may help a robot recover from an awkward grasp or unexpected obstacle, but the robot receives greater credit when it can perceive the situation, plan the next step, recover from variation and finish the sequence independently. The competition consequently measured operational autonomy as well as physical ability.
From robot demonstrations to commercial workflows
Hotel service is a useful commercialization test because it resembles a recognizable job rather than an isolated benchmark. One short assignment can expose weaknesses in locomotion, visual understanding, manipulation, safety, timing and long-horizon planning. Organizers framed the scenario events as tests of real-world workflows, bringing humanoid robotics closer to practical deployment. 8
10
The hotel contest was one of 21 scenario-based events spanning nine application areas: home cleaning, hotel service, industrial production, emergency rescue, library management, retail, office service, garden inspection and vehicle charging. 8
34 These settings focus on work that can be repetitive, standardized, physically demanding or difficult, while also reflecting operational pressures such as labor shortages, rising labor costs and high turnover.
5
8
37
Taken together, the events act as a capability map for robot workers. They show developers and potential customers which tasks are already tractable, which require human intervention and where reliability still falls short of commercial expectations.
Why the hotel venue mattered
Beijing Wuzhou Hotel was reported to use delivery robots, smart cabinets and an AI switchboard, while exploring further robotic services such as luggage handling, guest interaction and coffee making. 13 That makes the venue relevant to the test: it already represents a digitally enabled hospitality environment rather than a generic competition floor.
A working hotel also provides the kind of variability that robots must eventually handle. Corridors are constrained, rooms are not perfectly identical, objects may be positioned differently and people can move through the environment unexpectedly. Repeated testing in such settings can expose failures that remain hidden in carefully controlled demonstrations.
The 30-minute contest did not prove that humanoid robots are ready to replace hotel staff. It did show a more demanding direction for evaluation: robots are increasingly being judged on whether they can complete useful, multi-step work independently, safely and consistently in the environments where that work actually happens.
Studio Global AI
Continue your research
This page includes a source-backed answer you can continue inside Studio Global.
People also ask
What is the short answer to "How Humanoid Robots Were Tested on Hotel Work at the World Humanoid Robot Games"?
At the second World Humanoid Robot Games, hotel robots had 30 minutes to move luggage, restock a guest room and tidy a bed.
What are the key points to validate first?
At the second World Humanoid Robot Games, hotel robots had 30 minutes to move luggage, restock a guest room and tidy a bed. The challenge combined heavy load balance, grasping, navigation, obstacle avoidance and long chain planning in a real hotel environment—not isolated laboratory motions.
What should I do next in practice?
Soft bedding, narrow corridors, clutter and shifting loads exposed the gap between a convincing robot demonstration and dependable commercial service.
Sources
english.news.cnFeature: Scenario-based competitions bring humanoid robots closer to life
china.org.cnHumanoid robot games put real-world skills to the test - China.org.cn
pandaily.comRobots 'Pre-Employ' at Hotel Scenarios: World Humanoid Robot Games Tests Luggage, Restocking, and Bed-Making in 30 Minutes
eweek.comHumanoid Robots Make Beds, Move Luggage in China's Latest Work Test