AnswersPublished18 sources
How Boston Dynamics Trained Atlas to Lift and Carry a Mini‑Fridge
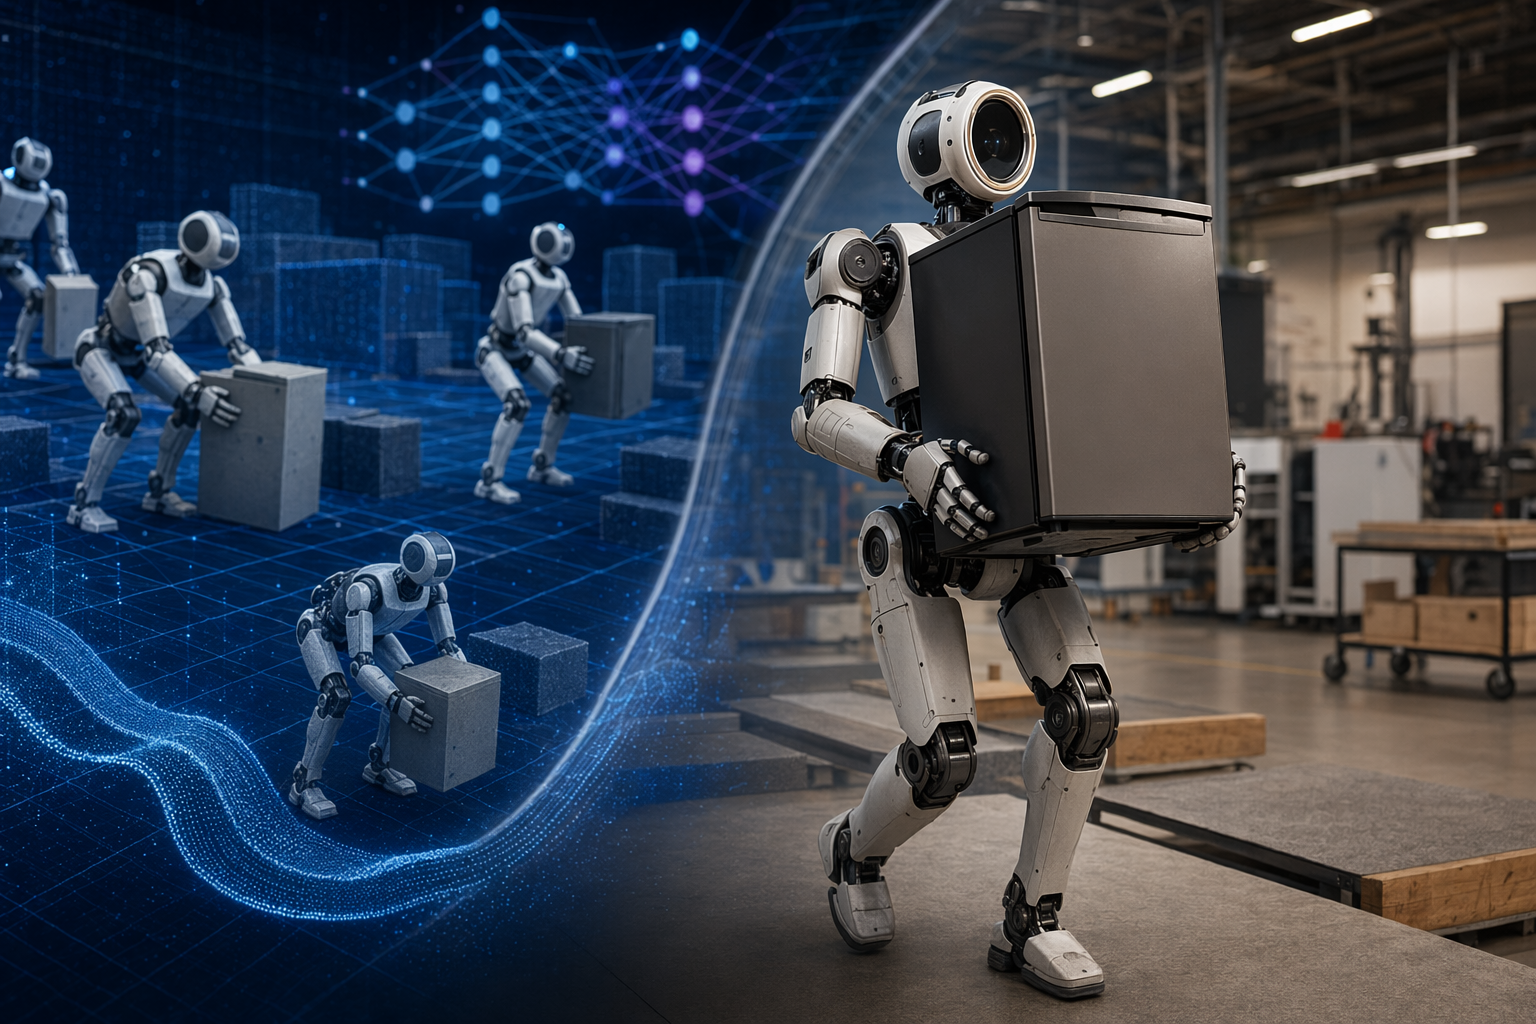
Boston Dynamics trained Atlas to lift and carry heavy objects by learning the behavior in large scale simulation using reinforcement learning, exposing the robot to many variations of object weight, friction, and grip... Proprioception—Atlas’s internal awareness of joint positions, forces, and body motion—lets the r...
Published byEdited with GPT-5.5
Research answer
Key takeaways
- Boston Dynamics trained Atlas to lift and carry heavy objects by learning the behavior in large scale simulation using reinforcement learning, exposing the robot to many variations of object weight, friction, and grip...
- Proprioception—Atlas’s internal awareness of joint positions, forces, and body motion—lets the robot maintain balance and adjust its grip while carrying heavy, shifting loads.
- Randomizing simulation physics (mass, friction, contact points) helps Atlas generalize to real‑world conditions, which is critical for industrial deployments where every object and surface differs slightly.
AI Prompt
openai.comCreate a landscape editorial hero image for this Studio Global article: How did Boston Dynamics train Atlas to lift and carry a 100-plus-pound mini-fridge using reinforcement learning and millions of GPU-powered. Article summary: Boston Dynamics trained Atlas by having it learn lifting-and-carrying behaviors in simulation with reinforcement learning, then applying those learned behaviors to the real robot [2][3]. The mini-fridge demo matters beca. Topic tags: general, general web, user generated. Reference image context from search candidates: Reference image 1: visual subject "Boston Dynamics showed off a prototype of its humanoid robot Atlas at CES 2026 and it walked along the stage showing off its moves. But the crowd also got a peek at the production" source context "Atlas, meet Atlas - TechCrunch" Reference image 2: visual subject "Boston Dynamics showed off a prototype of its human
Boston Dynamics’ recent demonstration of the Atlas humanoid robot lifting and carrying a mini‑fridge highlights a major shift in robotics: instead of hand‑programming movements, the robot learns complex physical tasks through reinforcement learning trained in simulation. The result is a controller capable of coordinating the robot’s entire body to handle heavy, awkward objects—exactly the kind of work expected in factories and warehouses.
Reinforcement Learning Instead of Hand‑Programmed Motion
Traditional industrial robots rely on carefully scripted motions. Atlas, by contrast, learns behaviors through reinforcement learning (RL). In this approach, a neural‑network policy repeatedly attempts a task in simulation, receives feedback about success or failure, and gradually improves through trial and error.
Studio Global AI
Continue your research
This page includes a source-backed answer you can continue inside Studio Global.
People also ask
What is the short answer to "How Boston Dynamics Trained Atlas to Lift and Carry a Mini‑Fridge"?
Boston Dynamics trained Atlas to lift and carry heavy objects by learning the behavior in large scale simulation using reinforcement learning, exposing the robot to many variations of object weight, friction, and grip...
What are the key points to validate first?
Boston Dynamics trained Atlas to lift and carry heavy objects by learning the behavior in large scale simulation using reinforcement learning, exposing the robot to many variations of object weight, friction, and grip... Proprioception—Atlas’s internal awareness of joint positions, forces, and body motion—lets the robot maintain balance and adjust its grip while carrying heavy, shifting loads.
What should I do next in practice?
Randomizing simulation physics (mass, friction, contact points) helps Atlas generalize to real‑world conditions, which is critical for industrial deployments where every object and surface differs slightly.
Sources
digg.comBoston Dynamics demonstrates Atlas robot lifting and carrying mini ...
interestingengineering.comBoston Dynamics reveals how Atlas lifts 100-pound industrial loads
ctco.blogInside Boston Dynamics' Atlas Reinforcement Learning Demo - CTCO
bostondynamics.comFlipping the Script with Atlas | Boston Dynamics